Pilot deployment
Fourier Intelligence
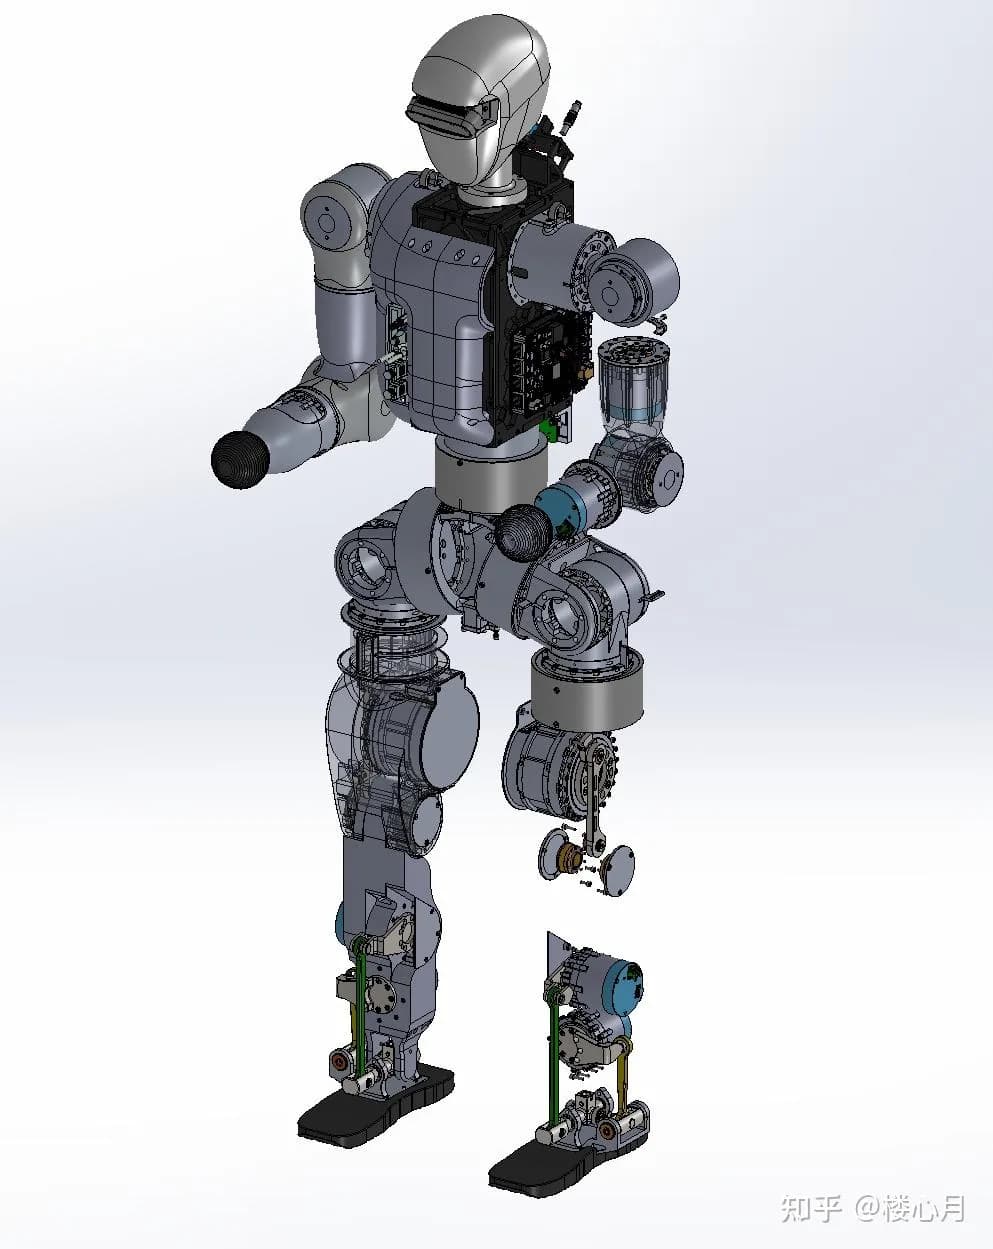
Fourier N1
The Fourier N1 is Fourier Intelligence's first open-source humanoid robot, released on April 11, 2025, and the…
Height130 cm
Degrees of freedom23
Arm payload—
Research
Price on request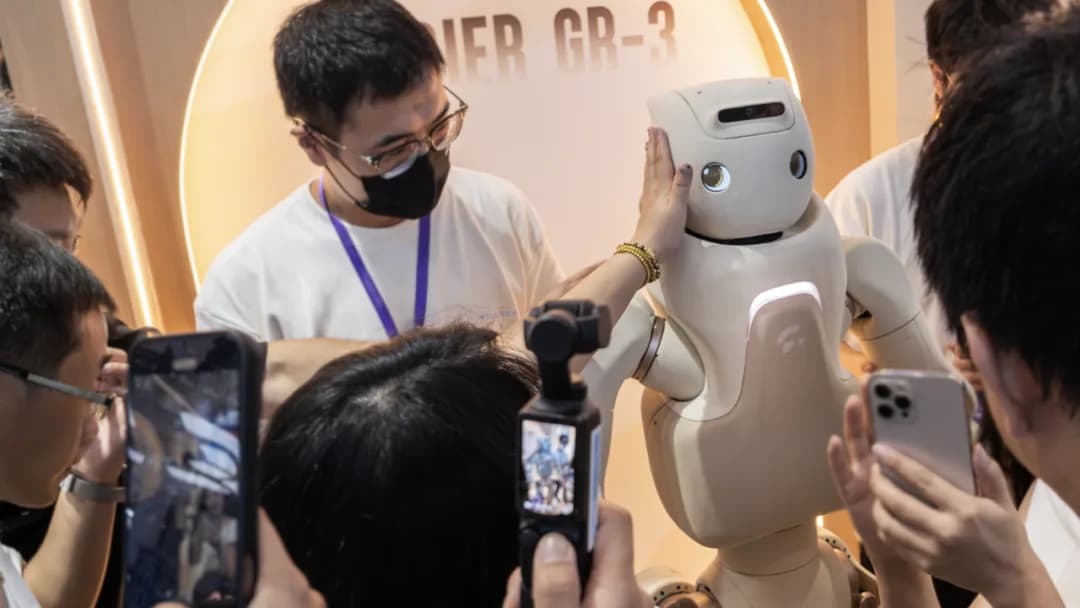
GR-3 is the third-generation full-size humanoid robot in Fourier's GRx series, launched on August 6, 2025, and Fourier's first Carebot — a companion robot built around interaction and designed to be touchable.
GR-3 is the third-generation full-size humanoid robot in Fourier's GRx series, launched on August 6, 2025, and Fourier's first Carebot — a companion robot built around interaction and designed to be "touchable".
GR-3 stands 165 cm tall, weighs 71 kg, has 55 degrees of freedom across the body and carries 3 kg per hand. Departing from the conventional metallic look, it uses Morandi warm-tone colors, soft skin-like upholstery and an animal-inspired head design; gentle facial curves, subtle two-eye expressions and soft body language soften the mechanical feel and create "technology companionship with warmth".
For interaction it carries an in-house full-sense interaction system that integrates hearing, vision and touch with an attention-management mechanism: 31 touch sensors provide real-time touch perception, a 4-microphone array captures sound omnidirectionally and locates the source, and structured-light plus RGB cameras enable face recognition and dynamic tracking. The system combines hard-coded programming with an LLM inference engine in a "dual-path response mechanism" that mimics human fast and slow thinking.
The battery uses a dual-battery hot-swap architecture, with dynamic energy allocation for uninterrupted swapping; each battery runs 3 hours, enabling 7×24 continuous operation. Preorders opened in September 2025, with deliveries from October, and a GR-3C version with a wraparound screen head and a reinforced hard shell is also offered. It is aimed mainly at rehabilitation institutions and nursing homes for chronic-disease care and daily assistance.
| Height | 165 cm |
|---|---|
| Weight | 71 kg |
| Material | Morandi warm-tone colors + supercar-grade interior upholstery + GFOAM soft foam padding (soft skin-like wrap) |
| Form factor | Full-size |
| Locomotion | Bipedal |
|---|---|
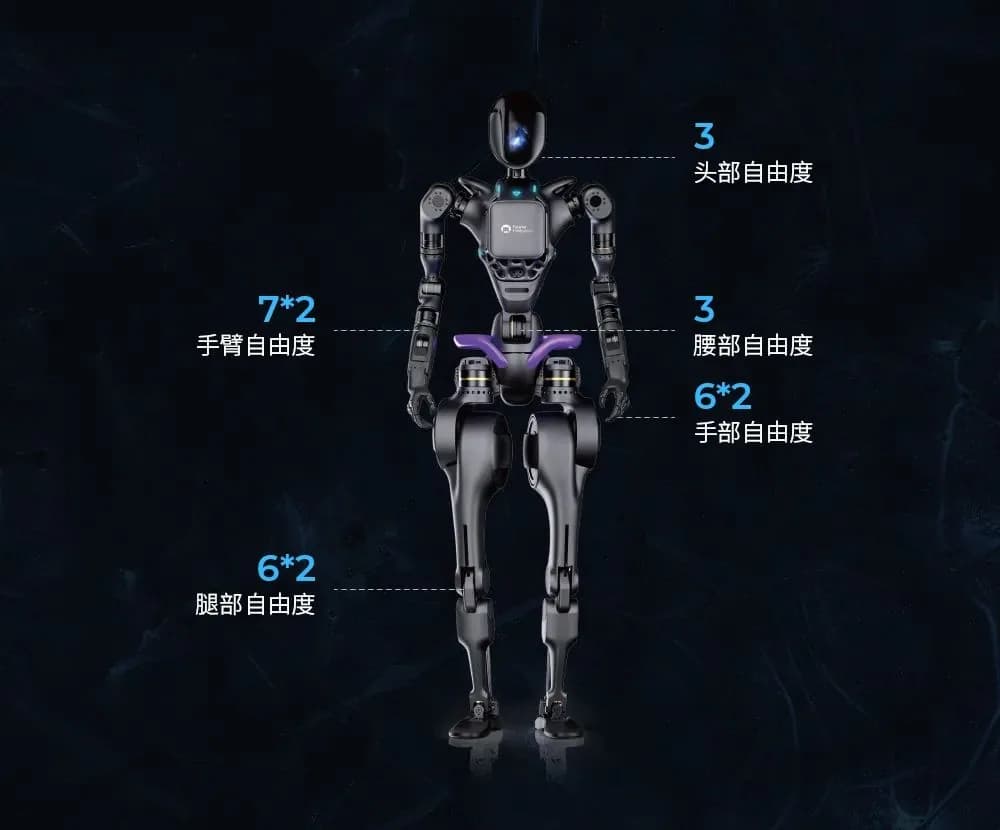
| Degrees of freedom | 55 |
| DOF breakdown | 55 total: 6 per leg, 7 per arm, 3 waist, 2 head, 6 per standard hand (12-DOF hand optional) |
| Arm payload | 3 kg |
| Top speed | 6.1 km/h |
| Battery life | 3 h |
| Battery swap | Yes |
| Peak joint torque | 440 N·m |
| Actuators | In-house high-performance integrated actuators plus multi-DOF dexterous hands |
| Speed notes | Supports multiple human-like gaits including straight-leg walking, a swaying gait, a quick shuffling trot and a tired mode |
| Battery notes | Each battery runs 3 hours (a 50% improvement over the previous generation); dual-battery hot-swap architecture with dynamic energy allocation for seamless swapping and 7×24 continuous operation |
| Compute | Full-sense interaction system (hard-coded programming plus an LLM inference engine in a "dual-path response mechanism", fast thinking/slow thinking) |
|---|---|
| Sensing | 31 touch sensors (head and torso) · 4-microphone array (omnidirectional pickup, sound-source localization) · Structured-light + RGB wide-angle camera module · Eye interaction / eyeball reflection (special-effect iris film) |
| Hands | Multi-DOF dexterous hands (in-house) |
| Hand DOF | 6 |
| Availability | Preorders opened 8 Sep 2025; price not announced |
|---|---|
| SDK | Fourier developer SDK |
| Software / OS | Full-Sense Interaction System; Ubuntu 22.04 |
| Deployments & partners | Care, companionship, reception and public-service pilots |
| Safety & certifications | Soft covering, force-limited joints and tactile sensing |
Claims on this profile are linked to primary reporting and manufacturer material where available.
Specifications are sourced from public materials and may change. Always confirm commercial terms with the manufacturer.
The Fourier N1 is Fourier Intelligence's first open-source humanoid robot, released on April 11, 2025, and the…
GR-1 is Fourier Intelligence's first general-purpose humanoid, unveiled on July 6, 2023 at the opening of WAIC…
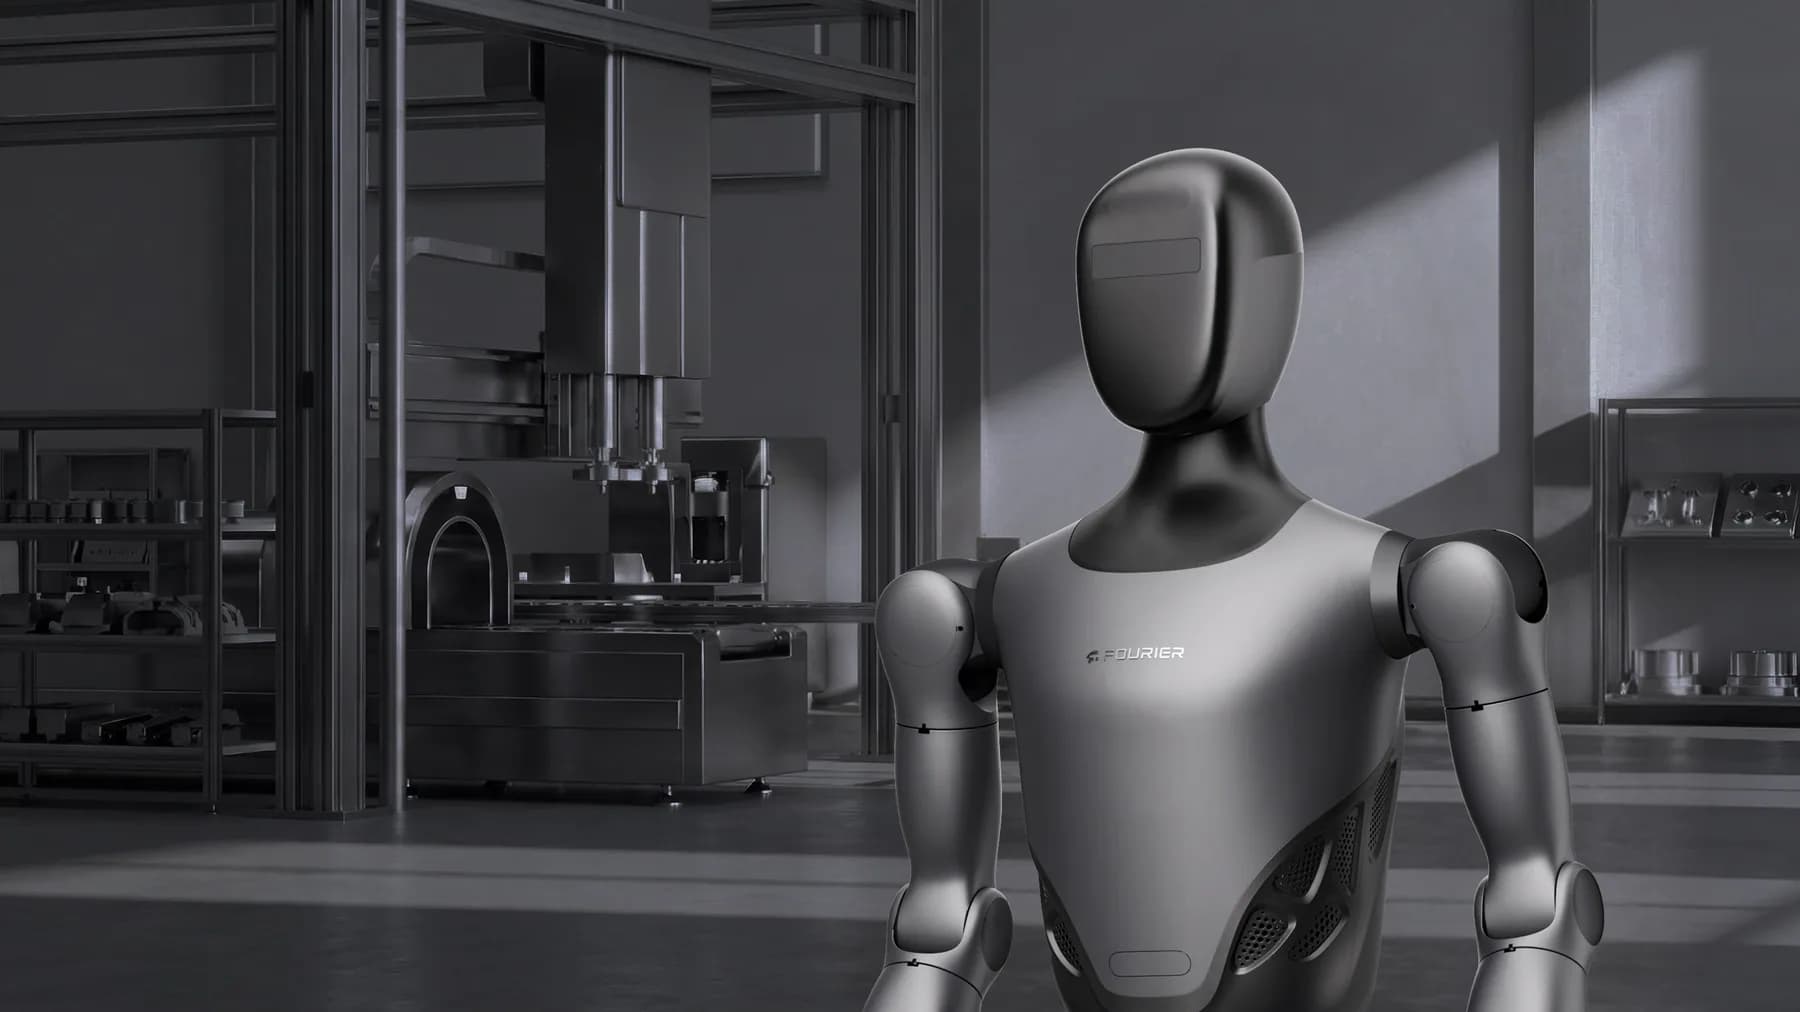
GR-2 is Fourier Intelligence's second-generation general-purpose humanoid, launched on September 26, 2024 in S…
UBTech's next-generation large humanoid service robot, globally unveiled at WAIC 2021 in Shanghai on July 7, 2…