Pilot deployment
Fourier Intelligence
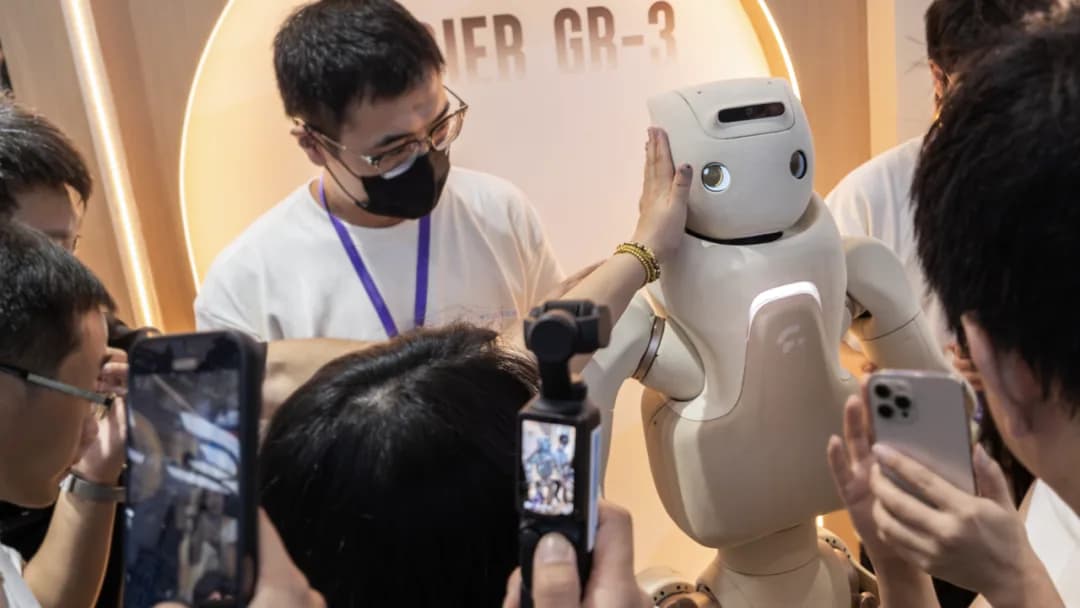
GR-3
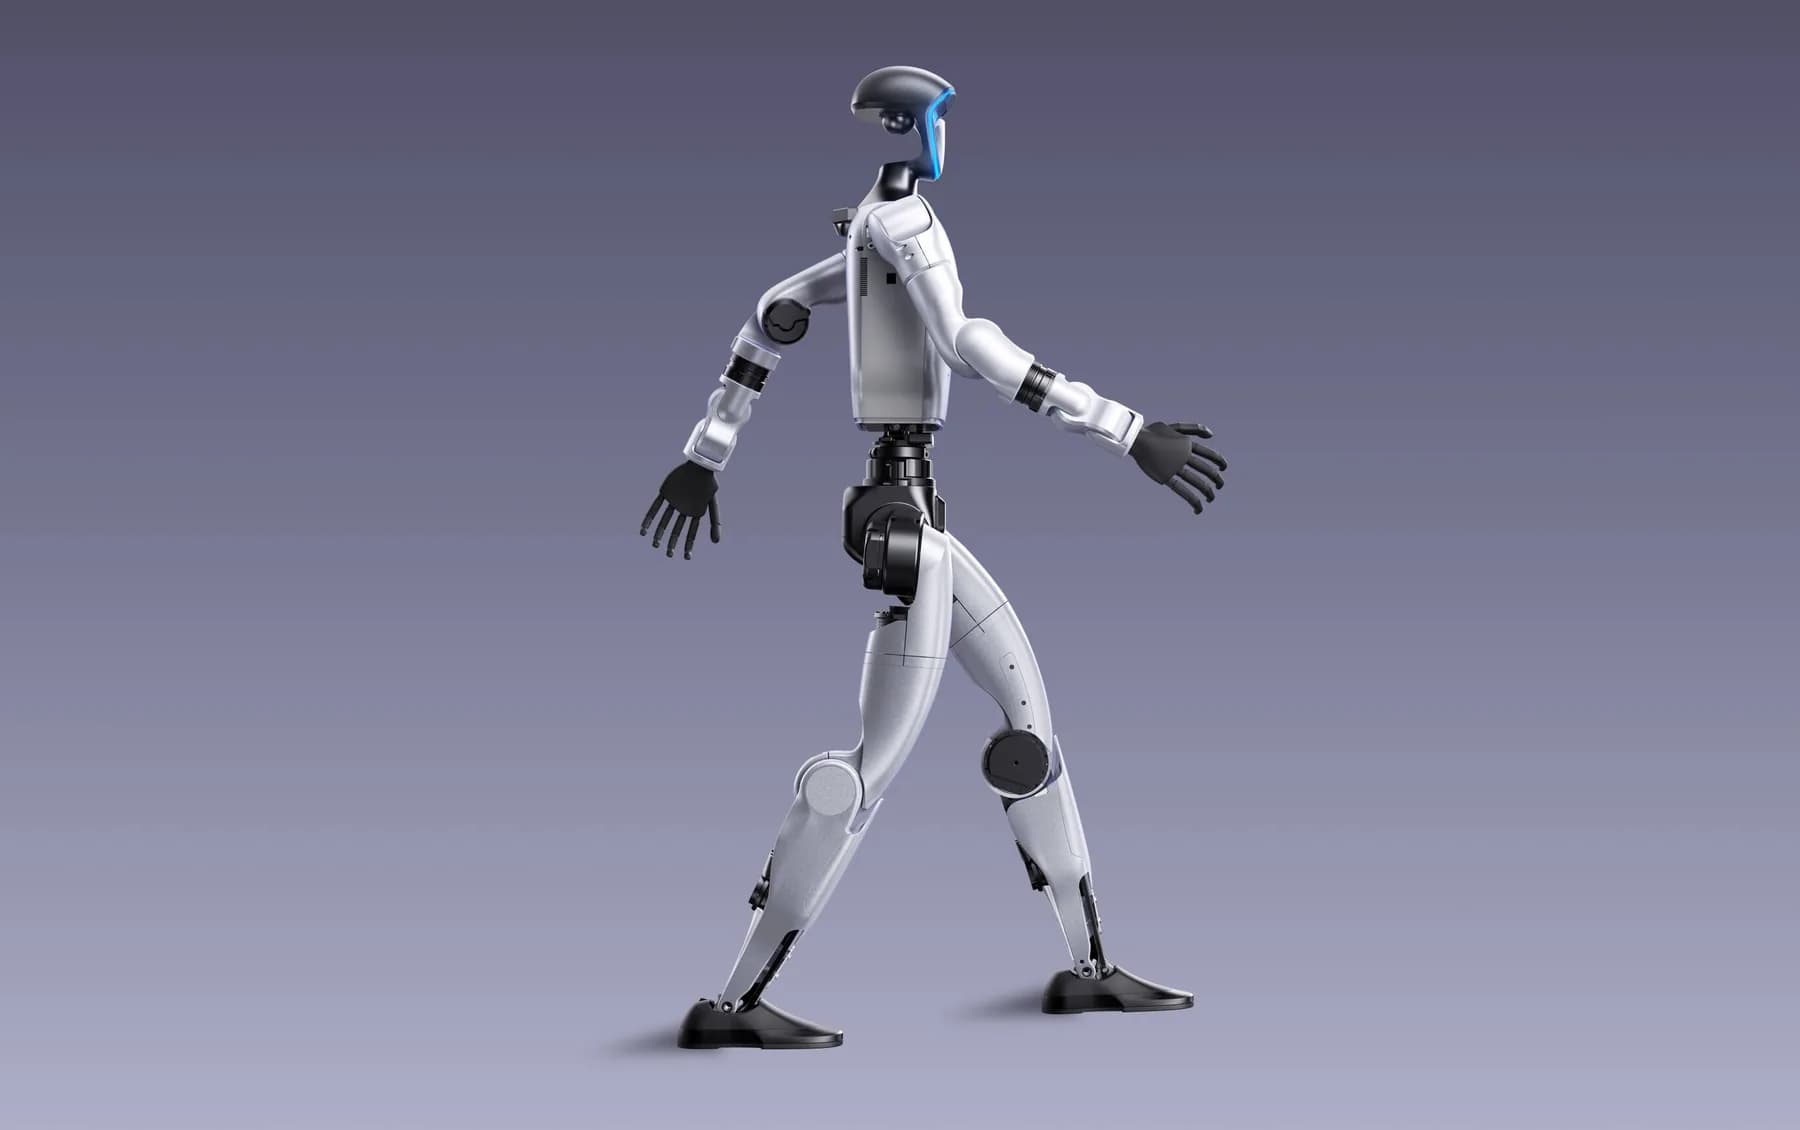
GR-3 is the third-generation full-size humanoid robot in Fourier's GRx series, launched on August 6, 2025, and…
Height165 cm
Degrees of freedom55
Arm payload3 kg
HomeHealthcare
Price on request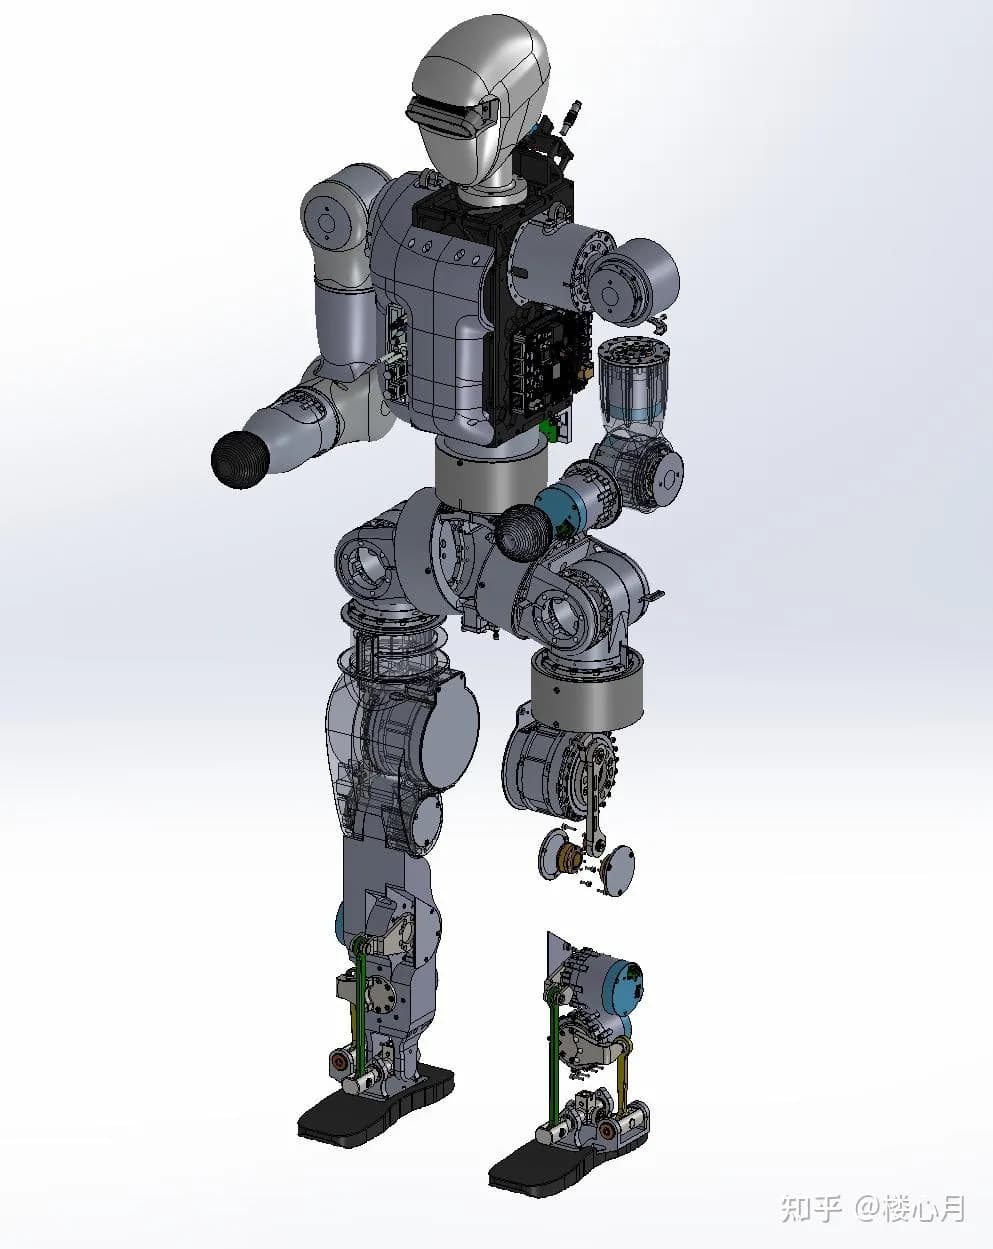
The Fourier N1 is Fourier Intelligence's first open-source humanoid robot, released on April 11, 2025, and the first project to land under its "Nexus open-source ecosystem matrix" (N1 stands for Nexus-01).
The Fourier N1 is Fourier Intelligence's first open-source humanoid robot, released on April 11, 2025, and the first project to land under its "Nexus open-source ecosystem matrix" (N1 stands for Nexus-01).
The N1 uses a compact hardware architecture: 1.3 m tall, 38 kg, and 23 degrees of freedom across the body (5×2 in the hands + 6×2 in the legs + 1 in the waist). High-cost components such as dexterous hands were removed to focus on motion performance. The body is built from a composite of aluminum alloy and engineering plastics and is driven by in-house FSA 2.0 integrated actuators.
In terms of mobility, the N1 reaches a maximum stable running speed of 3.5 m/s (12.6 km/h) and can handle 15°–20° slopes, climb 20 cm stairs, stand on one foot, and push itself up from the ground. A plug-in battery on its back provides more than 2 hours of runtime.
Fourier Intelligence has open-sourced a complete body resource package covering the bill of materials, design drawings, assembly guide and basic operating software, and plans to gradually release the inference code and training framework, giving embodied-AI developers worldwide an open technical foundation.
| Height | 130 cm |
|---|---|
| Weight | 38 kg |
| Material | Aluminum alloy + engineering plastic composite structure |
| Form factor | Compact |
| Locomotion | Bipedal |
|---|---|
| Degrees of freedom | 23 |
| DOF breakdown | Hands: 10 · leg: 12 · waist: 1 |
| Top speed | 12.6 km/h |
| Battery life | 2 h |
| Actuators | In-house FSA 2.0 integrated actuators |
| Speed notes | Maximum stable running speed 3.5 m/s (12.6 km/h) |
| Battery notes | Rear plug-in battery, more than 2 hours of continuous motion per charge |
| Compute | In-house real-time control system with a distributed bus architecture and millisecond-level response |
|---|---|
| Sensing | Vision sensors · Voice sensors · Tactile sensors (multimodal interaction) |
| Hands | High-cost dexterous-hand components omitted to focus on motion performance |
| Availability | Pilot deployments / limited availability |
|---|
Claims on this profile are linked to primary reporting and manufacturer material where available.
Specifications are sourced from public materials and may change. Always confirm commercial terms with the manufacturer.
GR-3 is the third-generation full-size humanoid robot in Fourier's GRx series, launched on August 6, 2025, and…
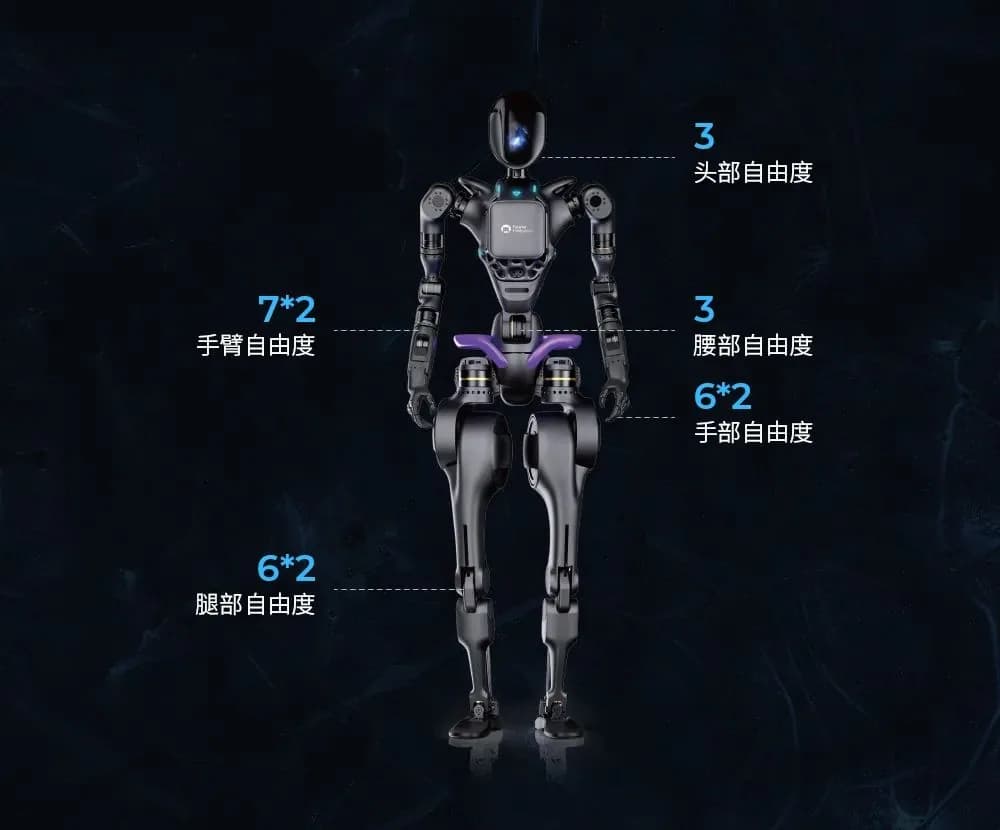
GR-1 is Fourier Intelligence's first general-purpose humanoid, unveiled on July 6, 2023 at the opening of WAIC…
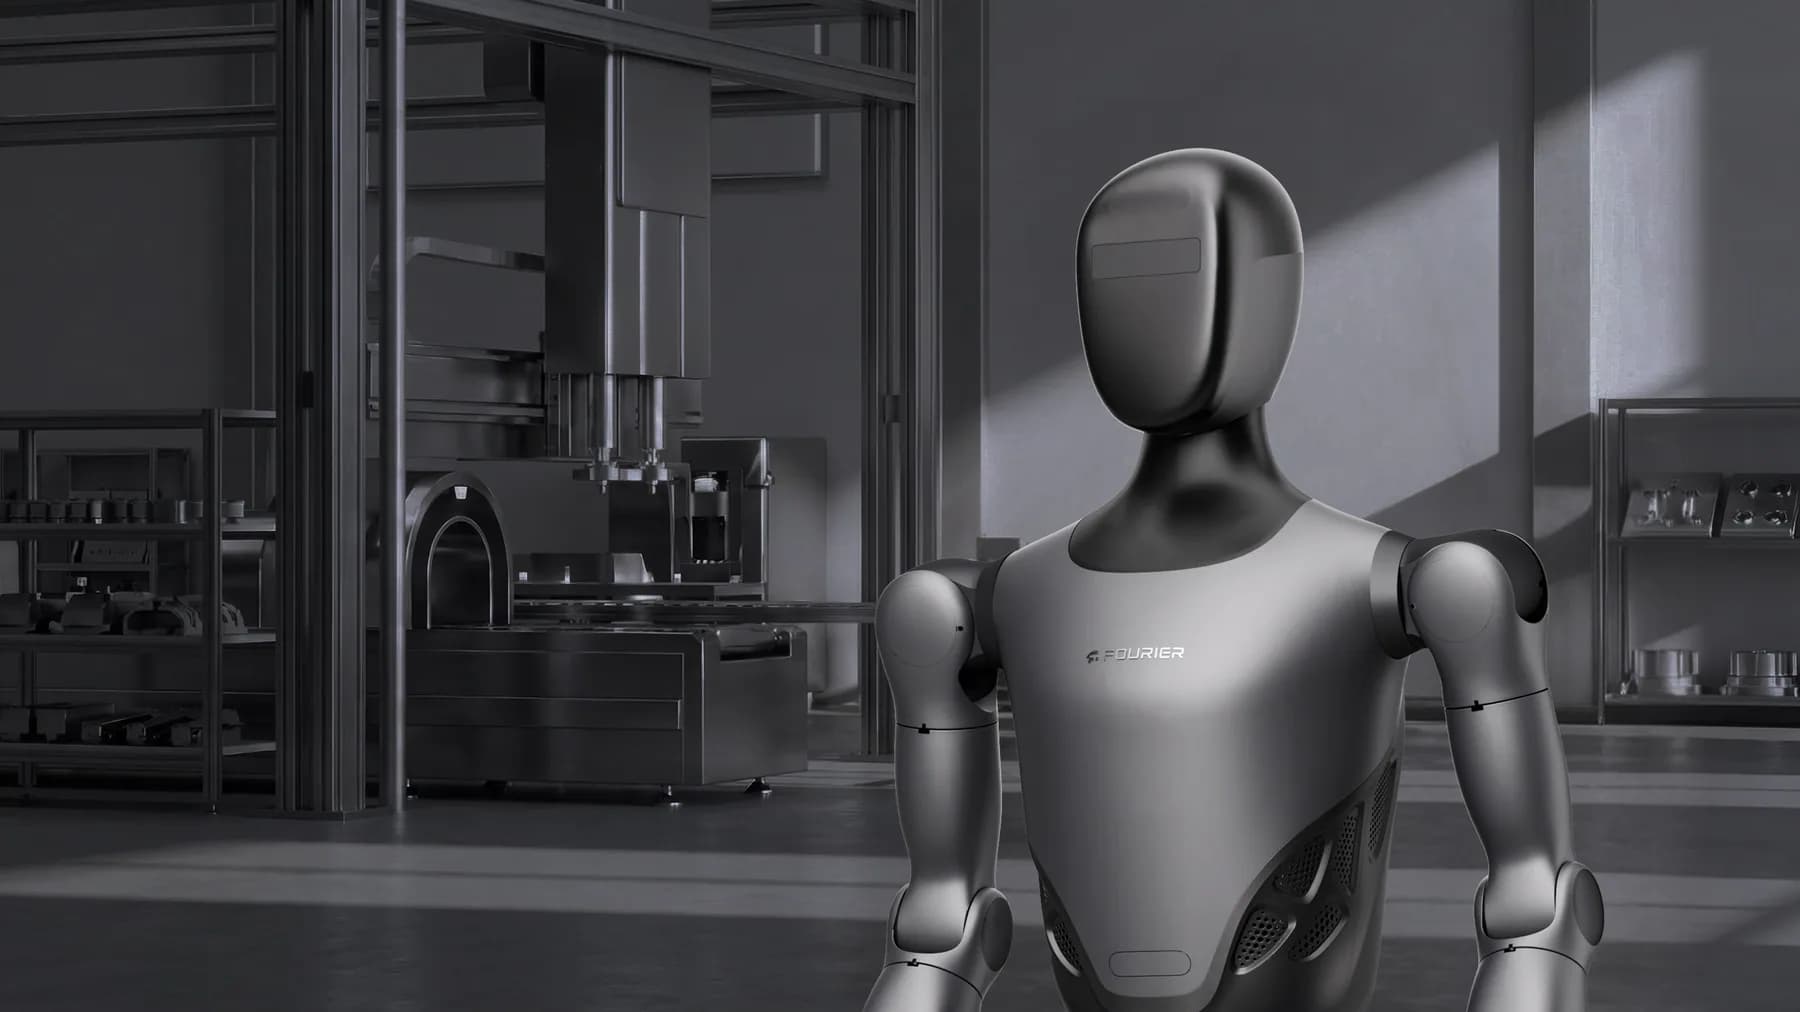
GR-2 is Fourier Intelligence's second-generation general-purpose humanoid, launched on September 26, 2024 in S…
Unitree's second humanoid robot and first small-scale model, launched on May 13, 2024 and billed by the compan…