Pilot deployment
Robot Era
L7
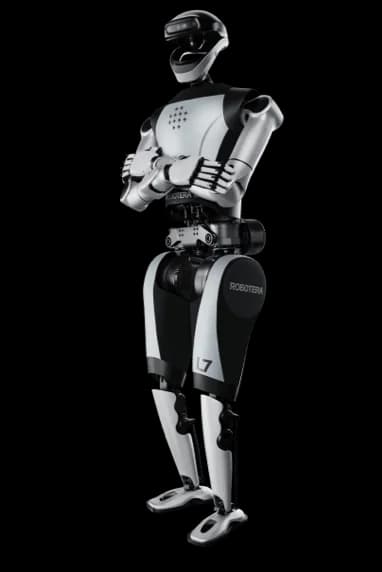
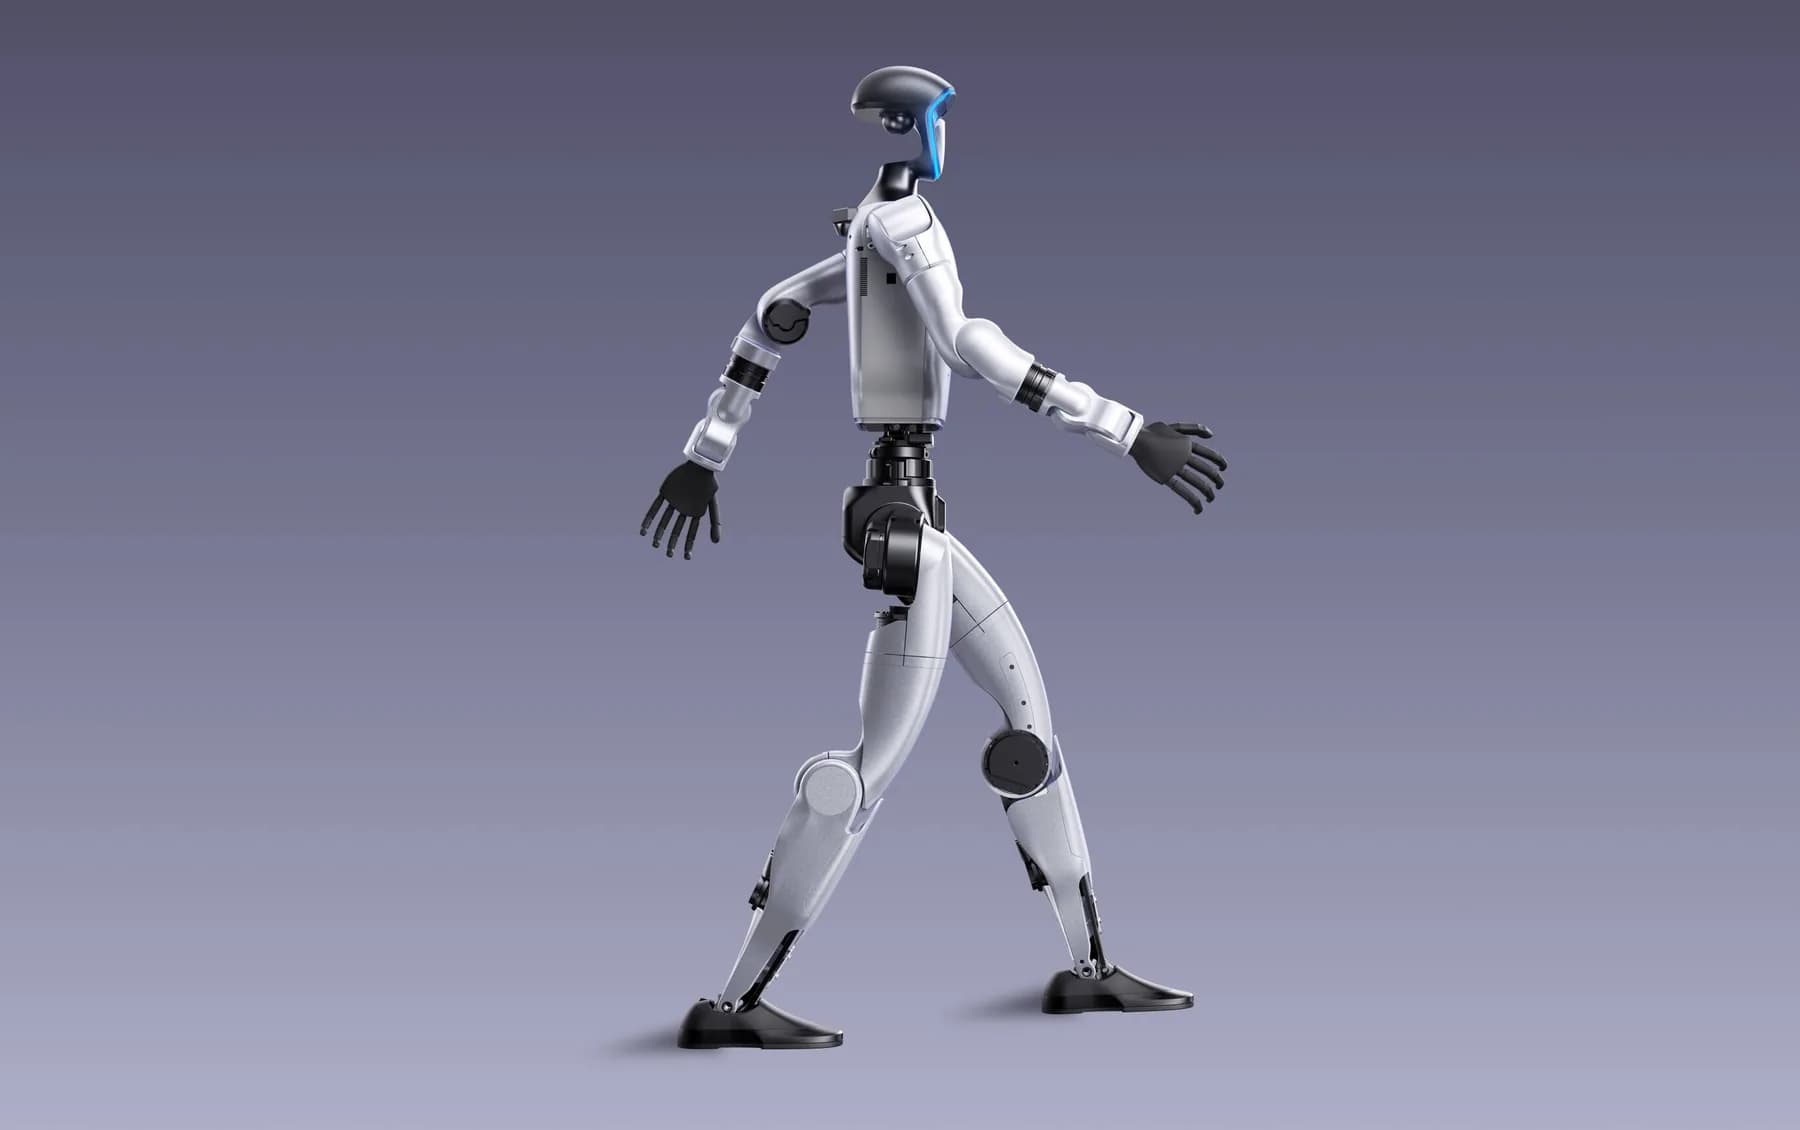
A 171 cm, 55-DOF full-size biped with 12-DOF hands, now sorting parcels in Chinese logistics hubs.
Height171 cm
Degrees of freedom55
Arm payload20 kg
LogisticsIndustrial
Price on request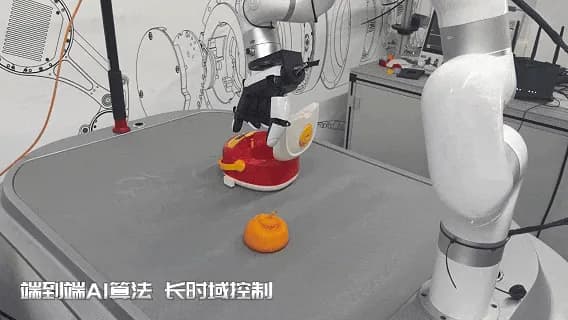
STAR1 is Robot Era's sixth-generation product-grade full-size high-performance general-purpose humanoid robot, launched on August 19, 2024, standing 171 cm tall, weighing 63 kg, with 55 fully active degrees of freedom.
STAR1 is Robot Era's sixth-generation product-grade full-size high-performance general-purpose humanoid robot, launched on August 19, 2024. It stands 171 cm tall, weighs 63 kg, and has 55 fully active degrees of freedom across its body (12 in the legs, 14 in the arms, 3 in the waist, 2 in the neck and 12 in each dexterous hand). It has a maximum joint torque of 400 N·m and a maximum joint speed of 25 rad/s, carries a maximum payload of 160 kg, and can climb and descend stairs, carry heavy loads, squat, jump, grasp and assemble.
| Height | 171 cm |
|---|---|
| Weight | 63 kg |
| Form factor | Full-size |
| Locomotion | Bipedal |
|---|---|
| Degrees of freedom | 55 |
| DOF breakdown | Leg: 12 · arm: 14 · waist: 3 · neck: 2 · hands: 24 |
| Full-body payload | 160 kg |
| Top speed | 13 km/h |
| Actuators | In-house high-torque-density joint modules; maximum joint torque 400 N·m and maximum joint speed 25 rad/s |
| Speed notes | 3.6 m/s in real outdoor scenarios (roughly a 4:38 per-kilometer pace); potential speed of 6 m/s |
| Compute | ERA-42 end-to-end native robot foundation model, fusing visual, auditory, tactile and other sensory information |
|---|---|
| Sensing | Depth camera · Inertial measurement unit (IMU), etc. |
| Hands | XHAND1 high-DOF dexterous hand (12 degrees of freedom per hand) |
| Availability | Pilot deployments / limited availability |
|---|
Claims on this profile are linked to primary reporting and manufacturer material where available.
Specifications are sourced from public materials and may change. Always confirm commercial terms with the manufacturer.
A 171 cm, 55-DOF full-size biped with 12-DOF hands, now sorting parcels in Chinese logistics hubs.
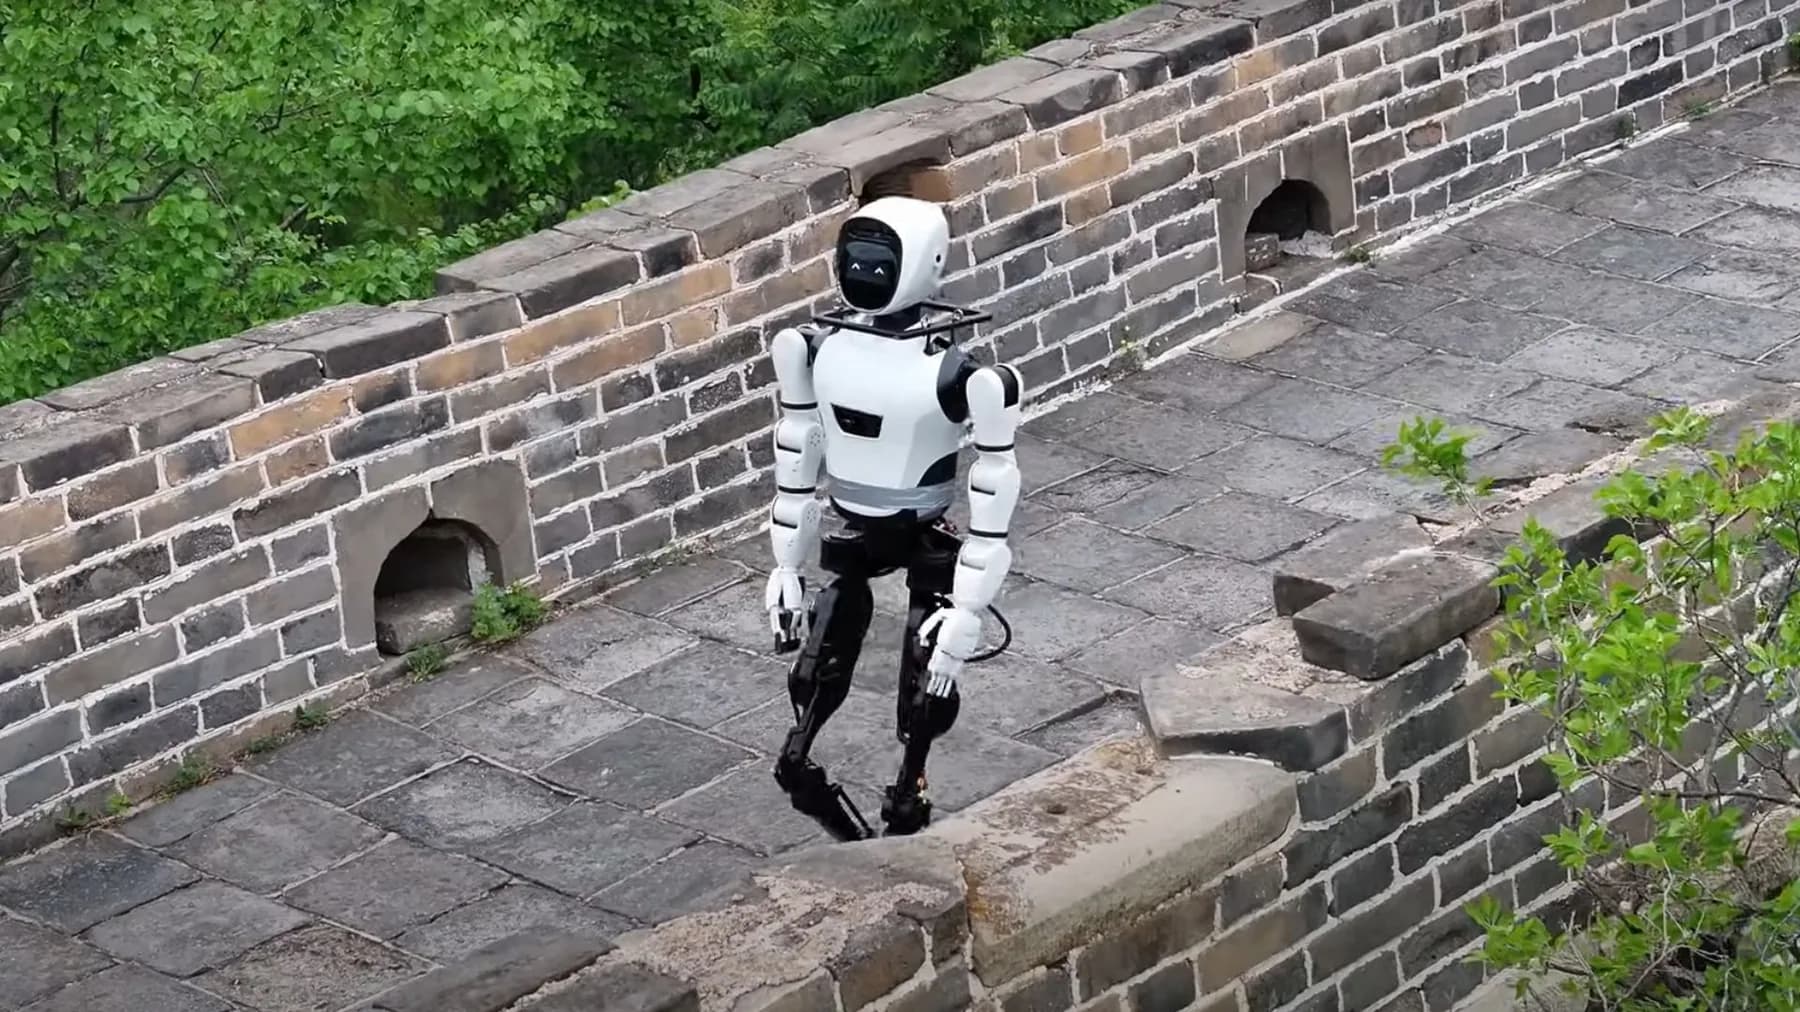
XBot-L (Xiaoxing Max) is a full-size humanoid robot from Robot Era, standing 1.65 m tall, weighing about 50 kg…
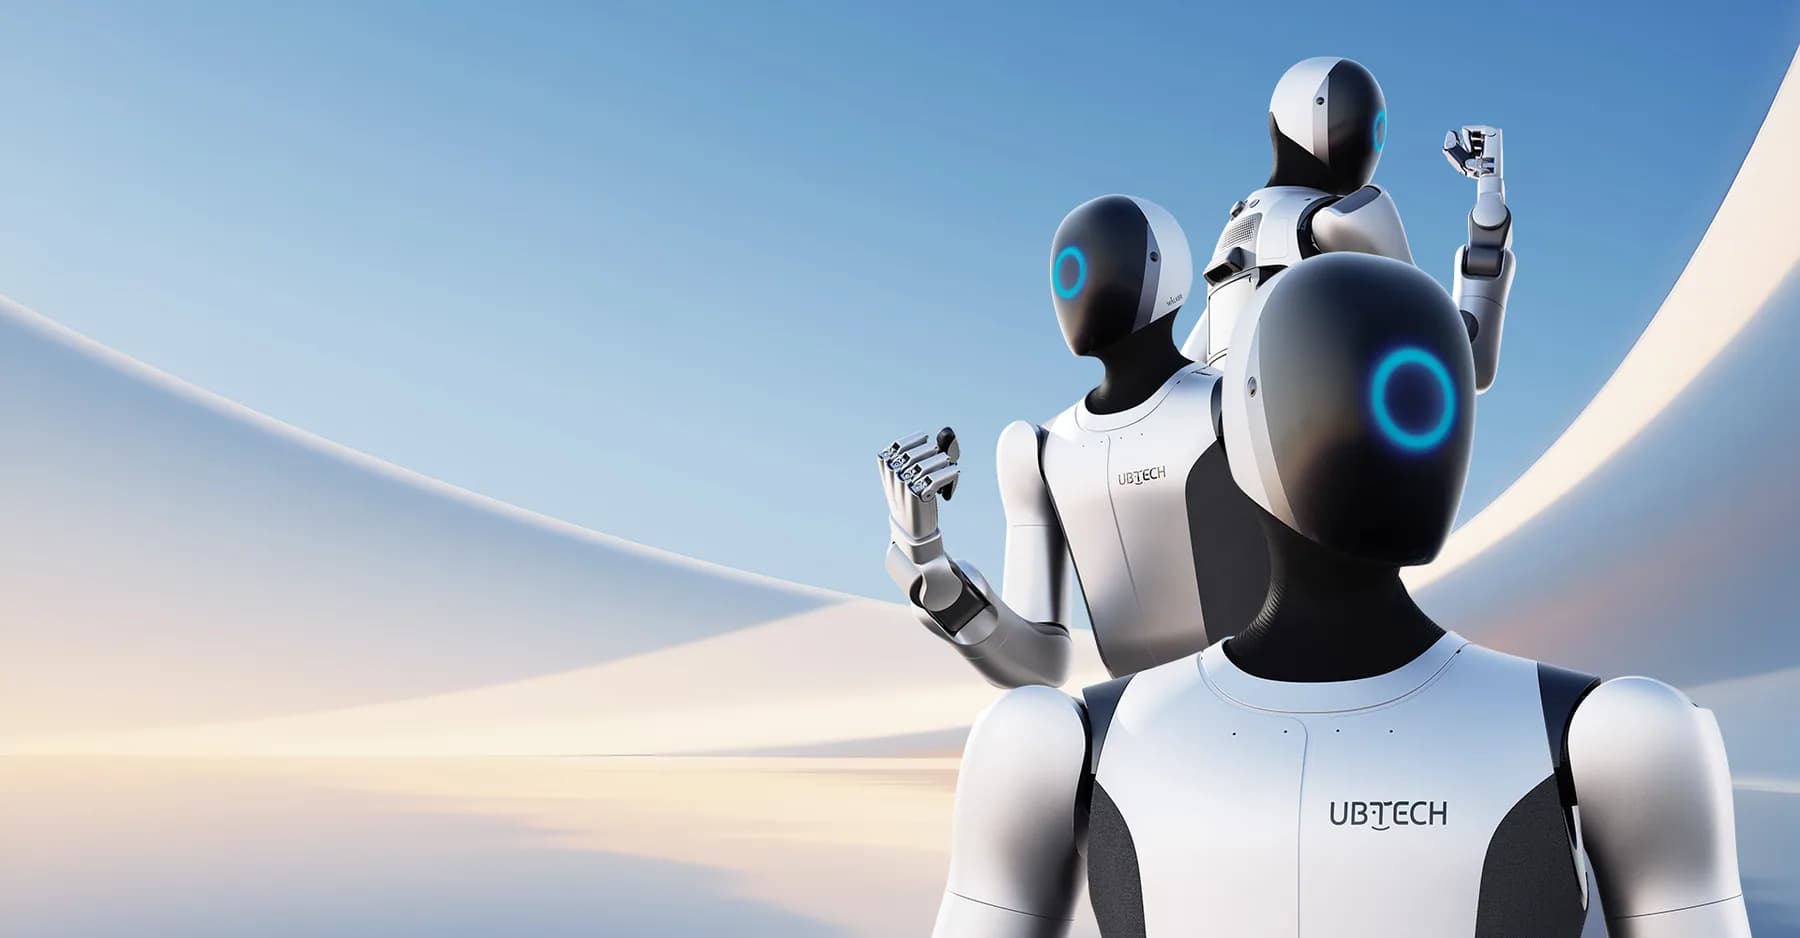
UBTech's all-new full-size industrial humanoid, launched on July 23, 2025, standing 176 cm and weighing 70 kg…
Unitree's second humanoid robot and first small-scale model, launched on May 13, 2024 and billed by the compan…