Public demo
MagicLab
MagicBot X1
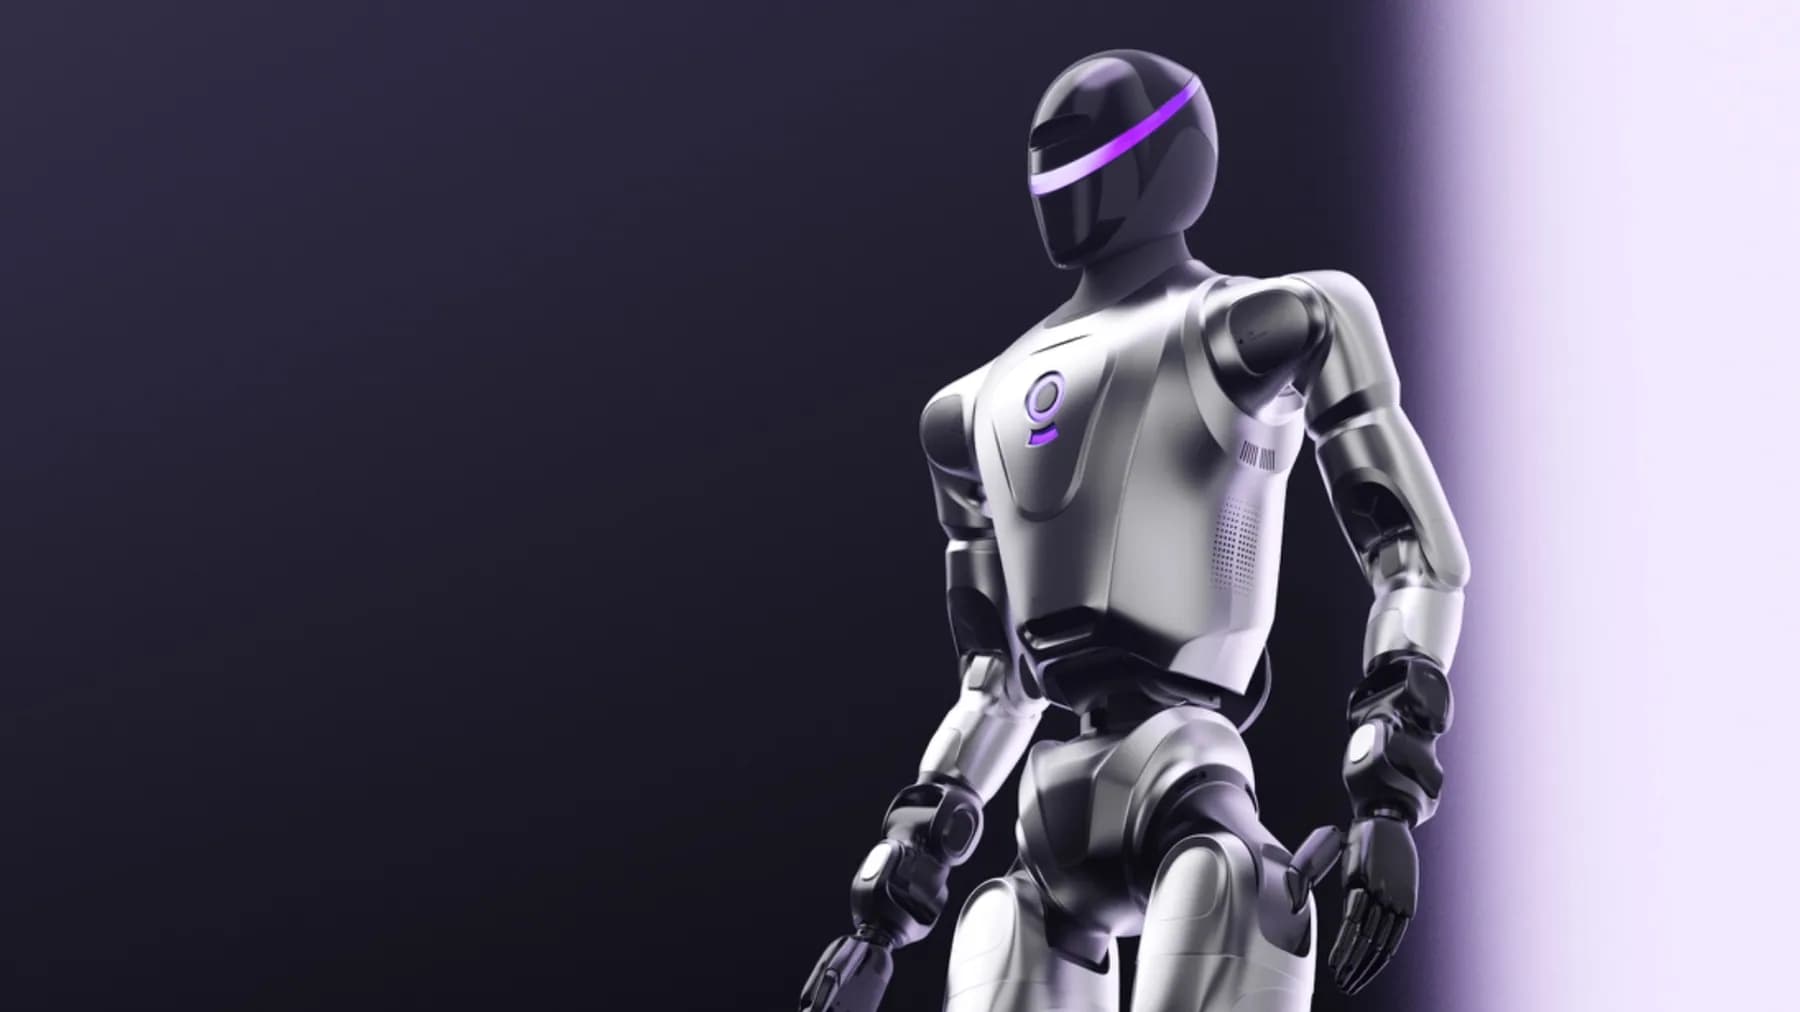
The MagicBot X1 is MagicLab's flagship full-size humanoid robot, debuting on the opening day of WRC 2026: 180…
Height180 cm
Degrees of freedom31
Arm payload—
InspectionIndustrial
Price on request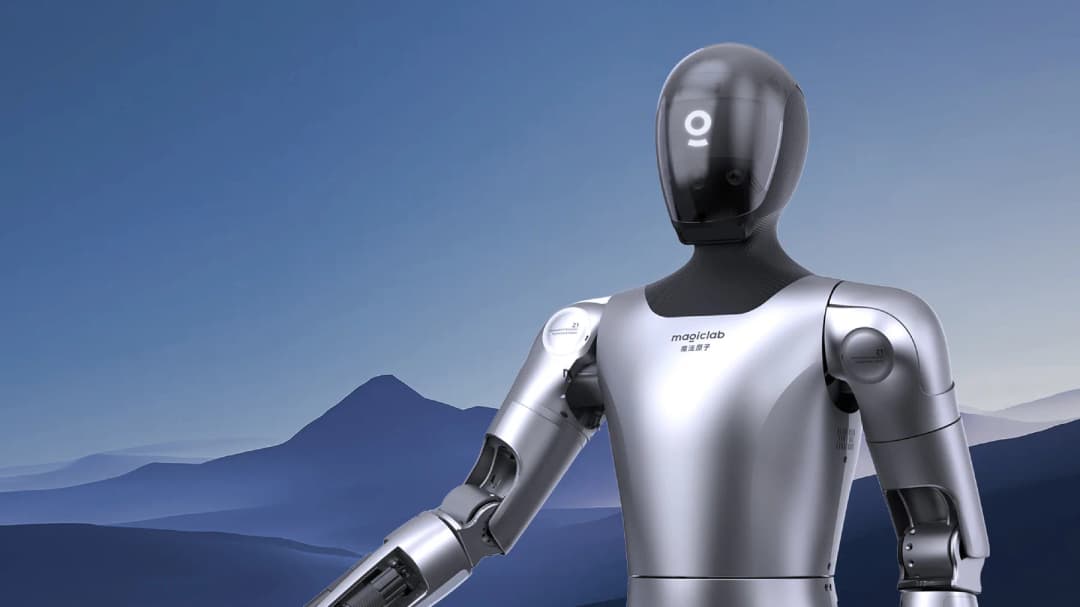
MagicBot (Xiaomai) is MagicLab's fully self-developed full-size humanoid robot: 174 cm tall, about 70 kg, 42 degrees of freedom, maximum joint torque ≥350 N·m and speeds of ≥4 km/h.
MagicBot (Xiaomai) is MagicLab's fully self-developed, full-size humanoid robot. It stands 174 cm tall, weighs about 70 kg, has 42 degrees of freedom across its body, delivers maximum joint torque of ≥350 N·m, and moves at ≥4 km/h. Its main structure is aluminum alloy, and it can perform human-like running in a single continuous take along with a straight-knee walking gait.
Xiaomai carries MagicLab's self-developed dexterous hands and the "AtomVerse" large model, allowing it to execute complex manipulation tasks. It is China's first general-purpose humanoid robot to achieve multi-robot collaboration, has already taken up work on factory production lines, and has served as a shopping guide and host, covering scenarios such as industrial manufacturing and commercial services.
| Height | 174 cm |
|---|---|
| Weight | 70 kg |
| Dimensions | Standing dimensions 1740×580×280 mm; arm span (shoulder to fingertip) 800 mm; lower leg + thigh 960 mm (510 + 450 mm) |
| Material | Aluminum-alloy main body + PC+ABS plastic shell |
| Form factor | Full-size |
| Locomotion | Bipedal |
|---|---|
| Degrees of freedom | 42 |
| Top speed | 4 km/h |
| Actuators | Harmonic and planetary reducers; maximum joint torque ≥350 N·m; in-house dexterous hands |
| Speed notes | Movement speed ≥4 km/h |
| Compute | Self-developed "AtomVerse" large model |
|---|---|
| Hands | In-house dexterous hands |
| Availability | Public demonstrations; not generally available |
|---|
Claims on this profile are linked to primary reporting and manufacturer material where available.
Specifications are sourced from public materials and may change. Always confirm commercial terms with the manufacturer.
The MagicBot X1 is MagicLab's flagship full-size humanoid robot, debuting on the opening day of WRC 2026: 180…
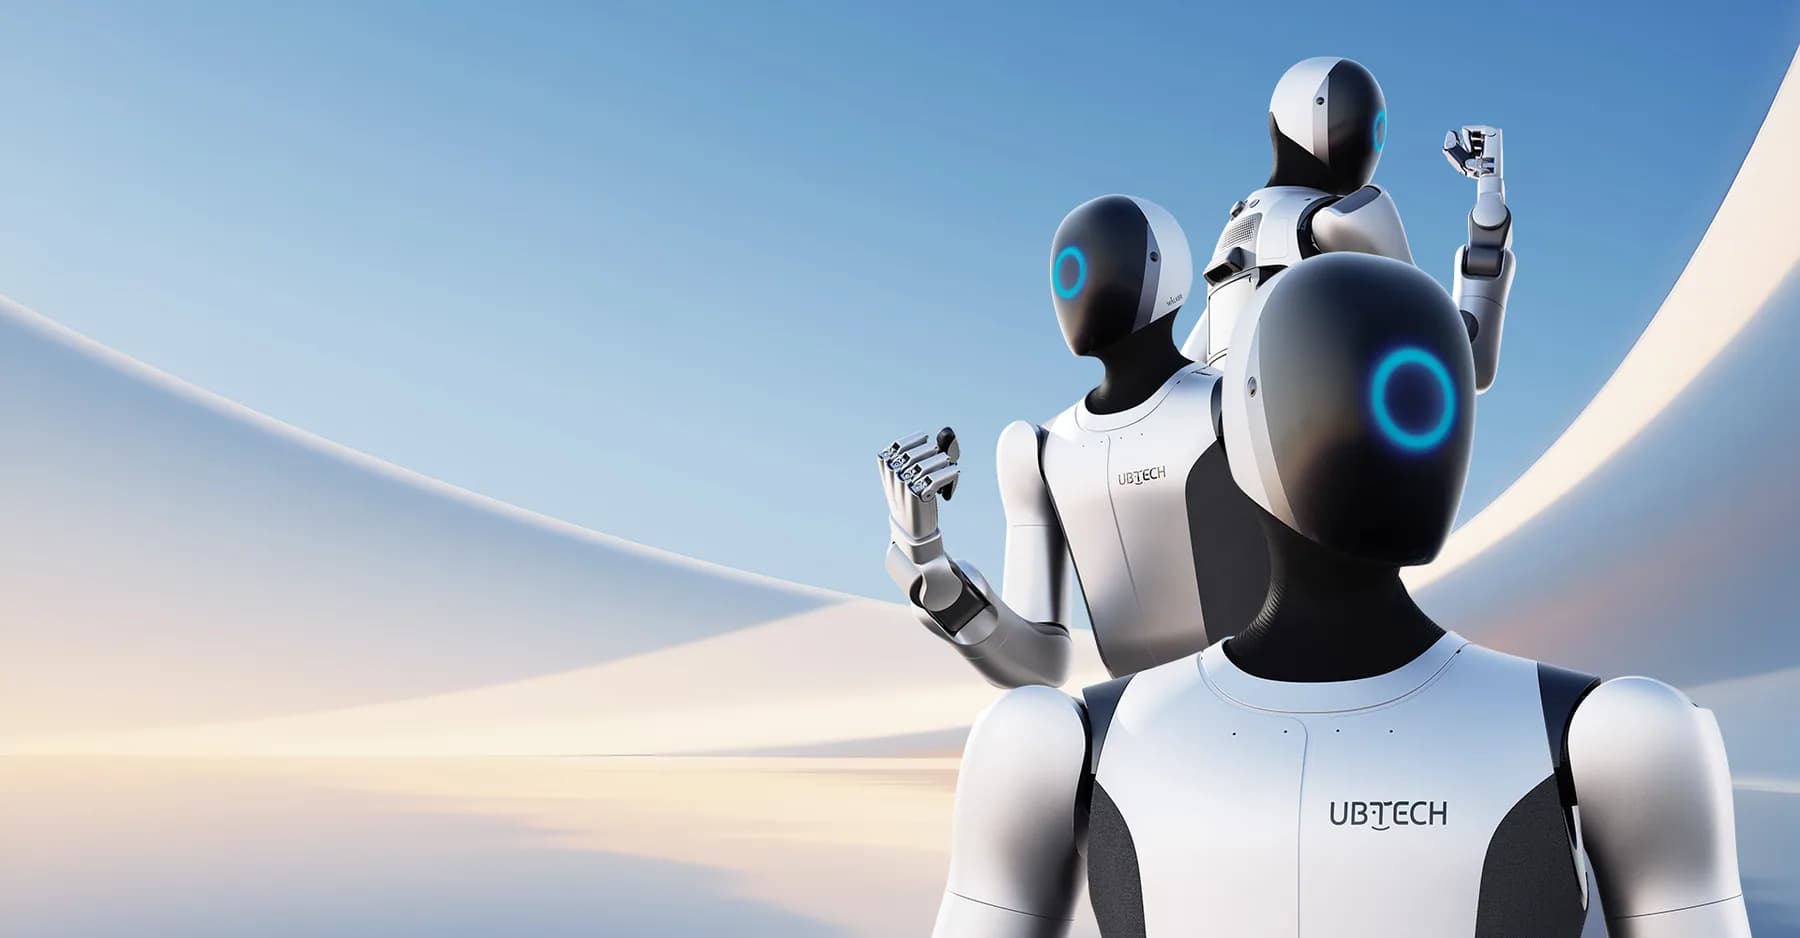
UBTech's all-new full-size industrial humanoid, launched on July 23, 2025, standing 176 cm and weighing 70 kg…
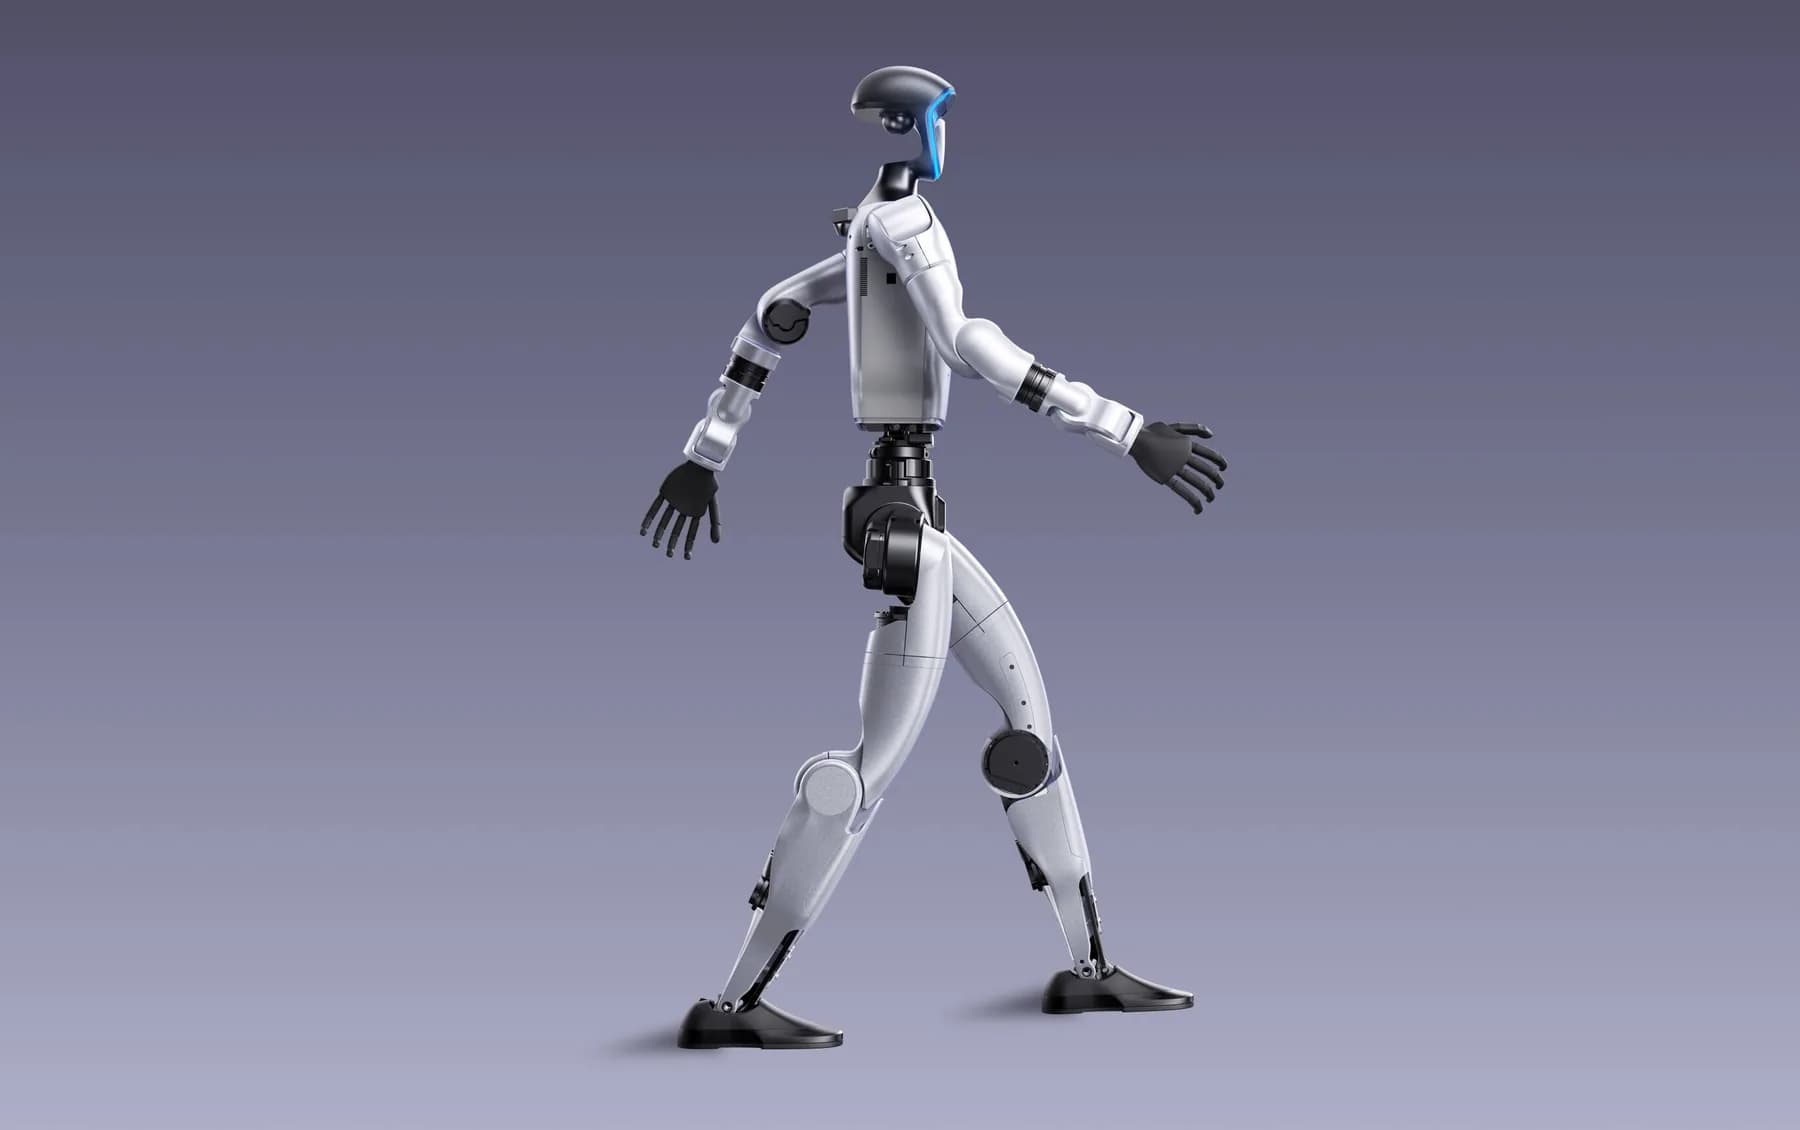
Unitree's second humanoid robot and first small-scale model, launched on May 13, 2024 and billed by the compan…
UBTech's next-generation large humanoid service robot, globally unveiled at WAIC 2021 in Shanghai on July 7, 2…