Pilot deployment
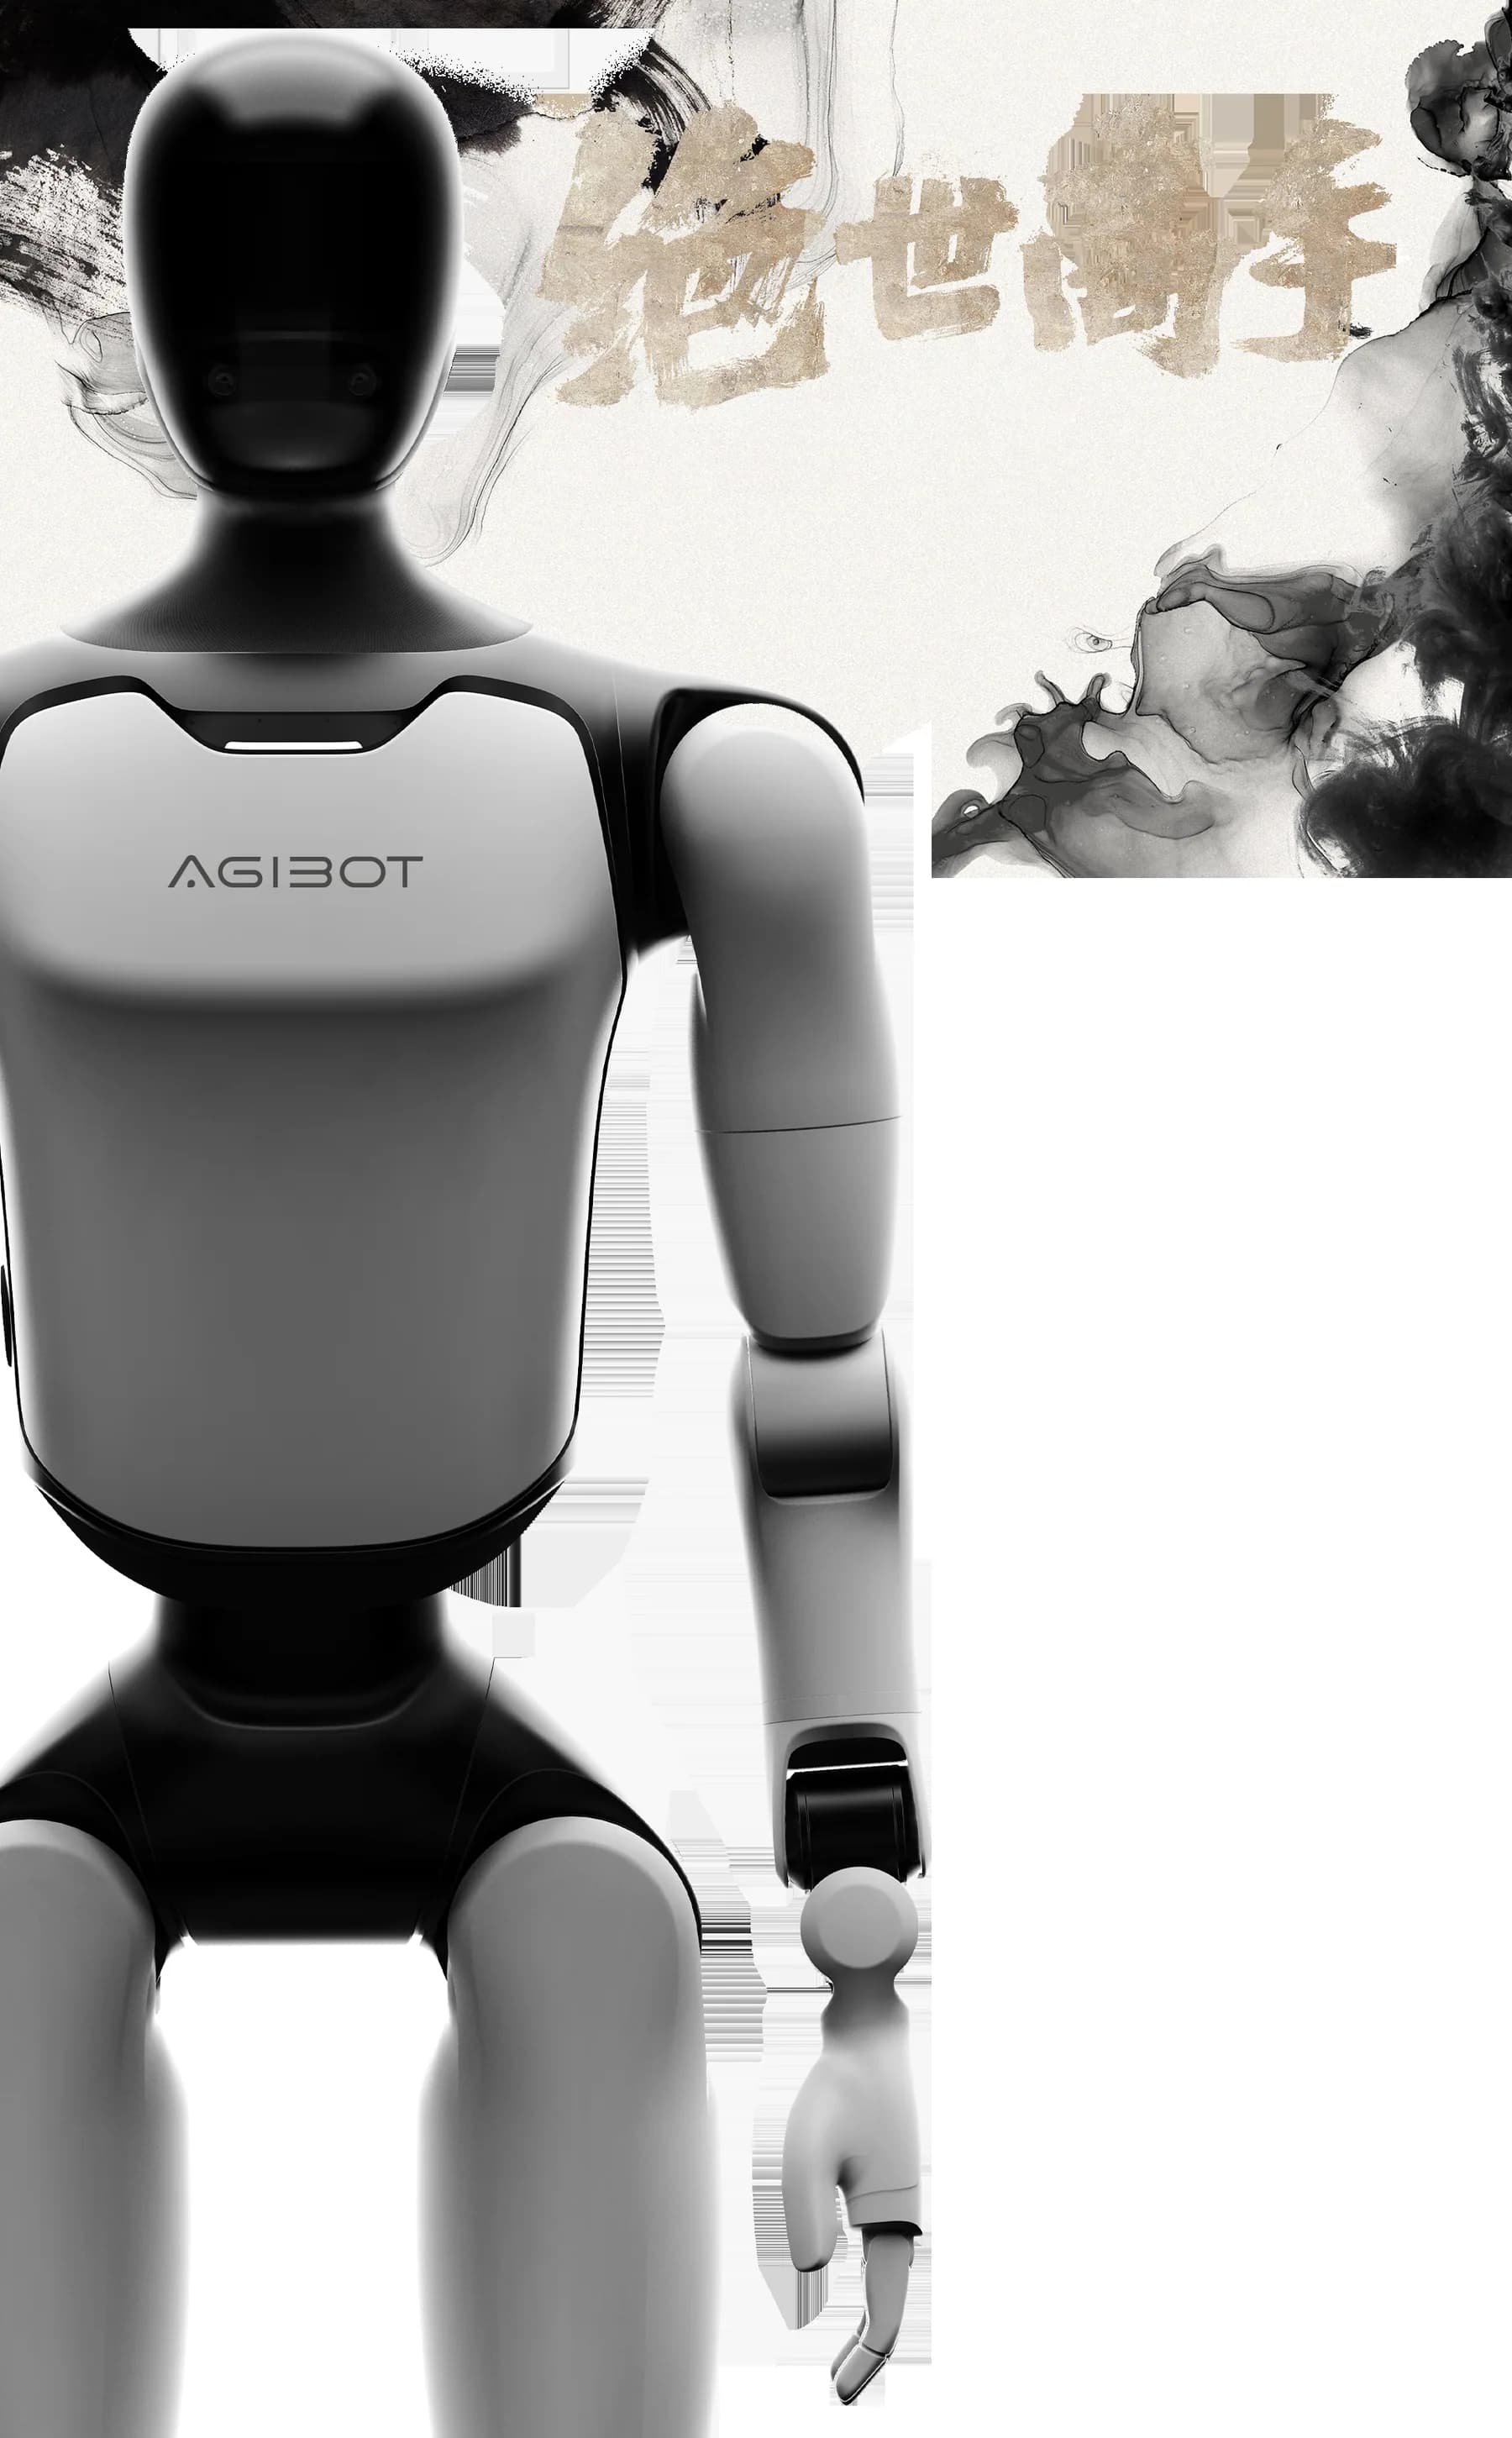
AgiBot
A3
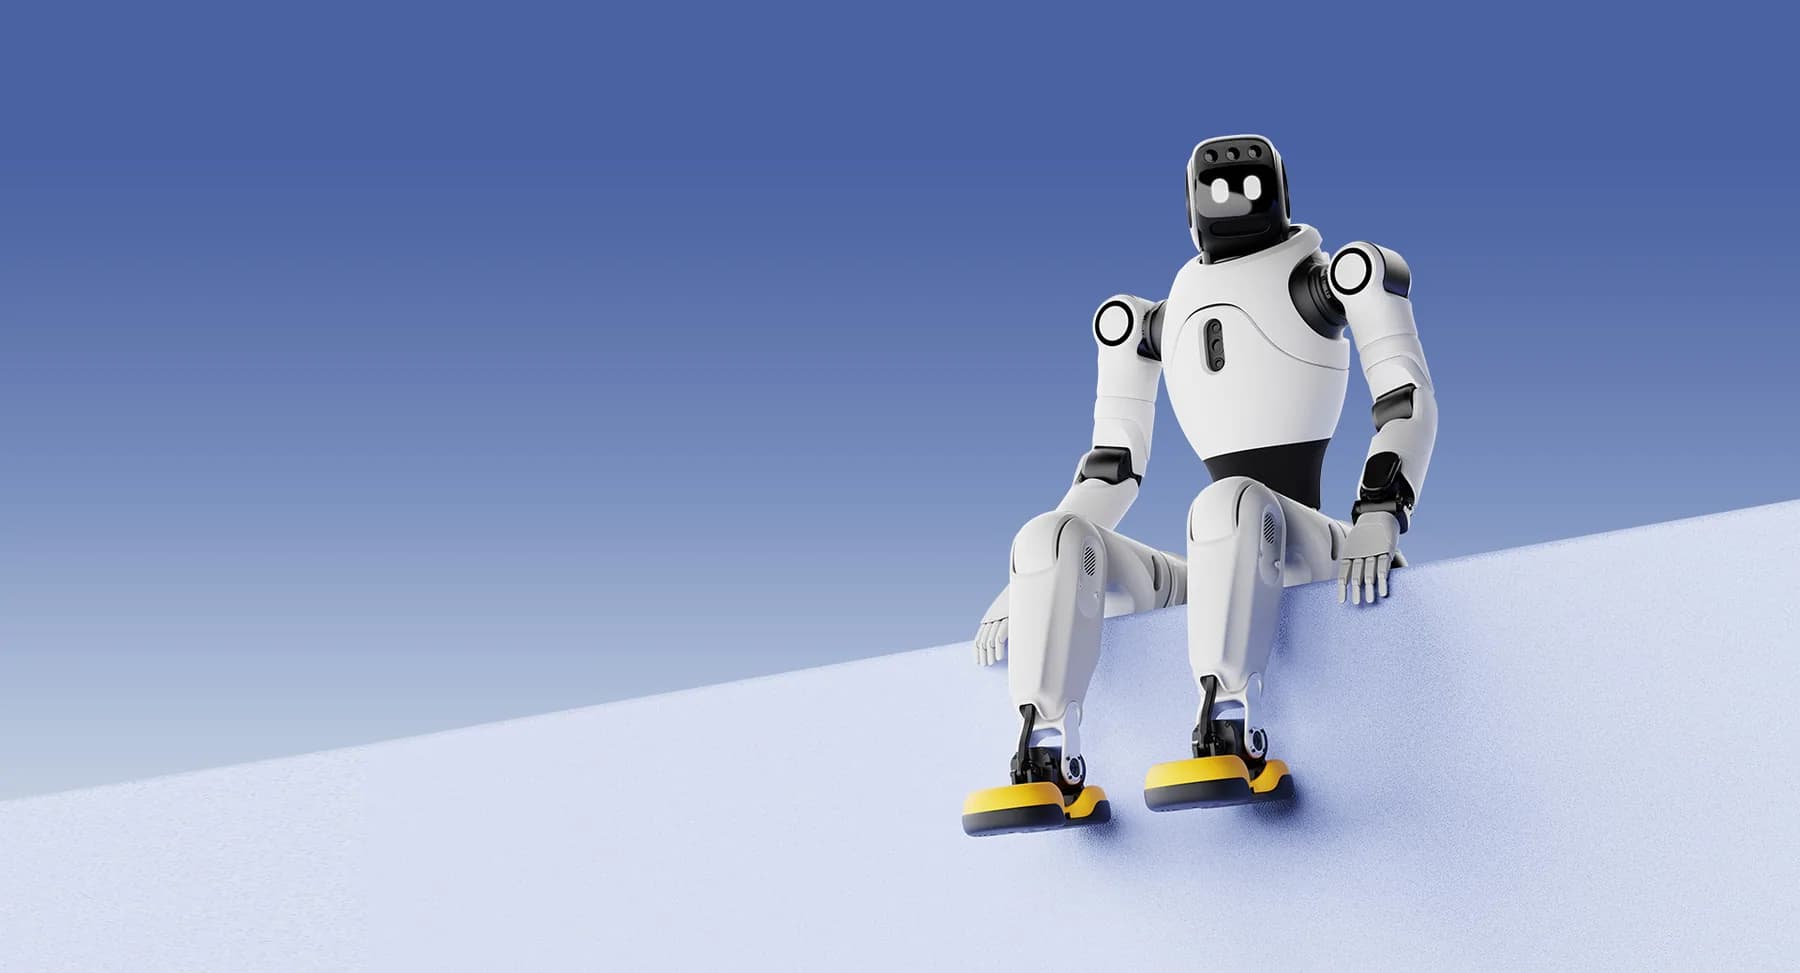
AgiBot's next-generation full-size humanoid, launched on February 13, 2026 for high-frequency human-robot inte…
Height173 cm
Degrees of freedom31
Arm payload5 kg
EntertainmentService & retail
Price on request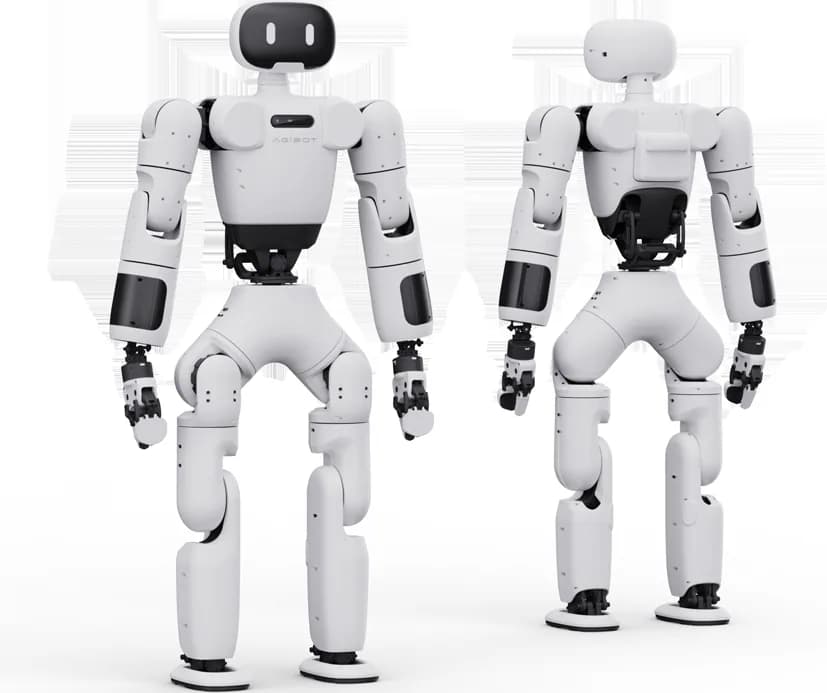
Lingxi X1 is a fully open-source humanoid robot incubated by AgiBot's X-Lab (nicknamed "Zhihui Jun's Lab"), launched on August 18, 2024 and built by a 10-person team in under three months.
Lingxi X1 is a full-stack open-source humanoid robot incubated by AgiBot's X-Lab (nicknamed "Zhihui Jun's Lab"). Launched on August 18, 2024, it was developed by a 10-person team in under three months and features modular design, high degrees of freedom, a safe and lightweight build, and strong expandability, making it an ideal choice for human-robot interaction and light service scenarios.
| Height | 130 cm |
|---|---|
| Weight | 33 kg |
| Form factor | Compact |
| Locomotion | Bipedal |
|---|---|
| Degrees of freedom | 31 |
| DOF breakdown | Waist: 3 · arms: 14 · legs: 12 |
| Arm payload | 0.5 kg |
| Top speed | 3.6 km/h |
| Battery life | 2 h |
| Actuators | In-house PowerFlow joint motors: R86-3 (200 N·m peak torque), R86-2 (80 N·m peak torque), R52 (19 N·m peak torque), L28 linear actuator (110 N maximum thrust) |
| Speed notes | Maximum walking speed 1 m/s |
| Battery notes | About 2 hours of runtime (battery capacity not published on the official site) |
| Compute | x86 main controller plus a domain controller unit (DCU) (EtherCAT to 3× FDCAN, 1 kHz real-time communication), with AimRT middleware |
|---|---|
| Hands | OmniPicker adaptive grippers ×2 (0.43 kg, 30 N maximum grip force, 120 mm maximum stroke) |
| Availability | Commercially available |
|---|
Claims on this profile are linked to primary reporting and manufacturer material where available.
Specifications are sourced from public materials and may change. Always confirm commercial terms with the manufacturer.
AgiBot's next-generation full-size humanoid, launched on February 13, 2026 for high-frequency human-robot inte…
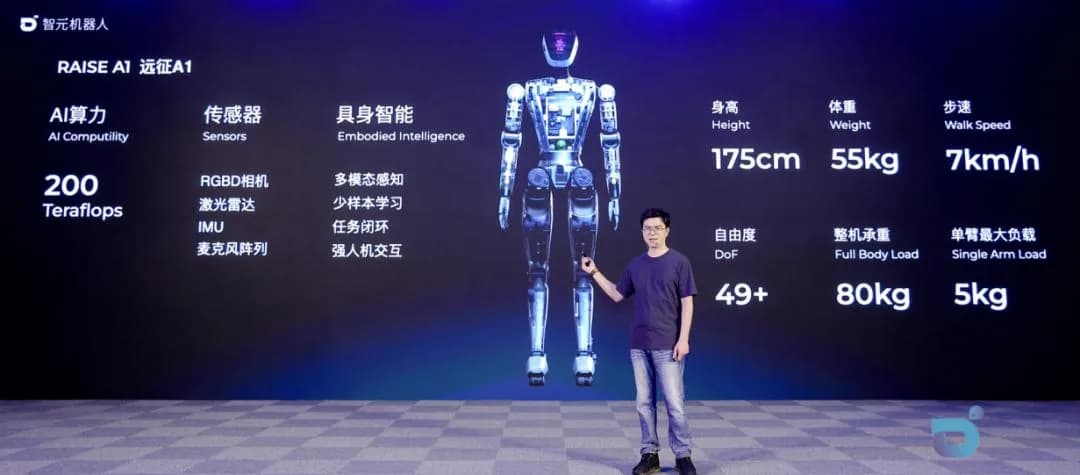
The A1 (Yuanzheng A1) was AgiBot's first general-purpose embodied-intelligence humanoid robot, unveiled in Sha…
The A2 (Yuanzheng A2) is AgiBot's second-generation commercial interactive service humanoid robot, launched on…
Lingxi X2 is AgiBot's next-generation emotionally interactive bipedal humanoid robot, launched on March 11, 20…