Mass production
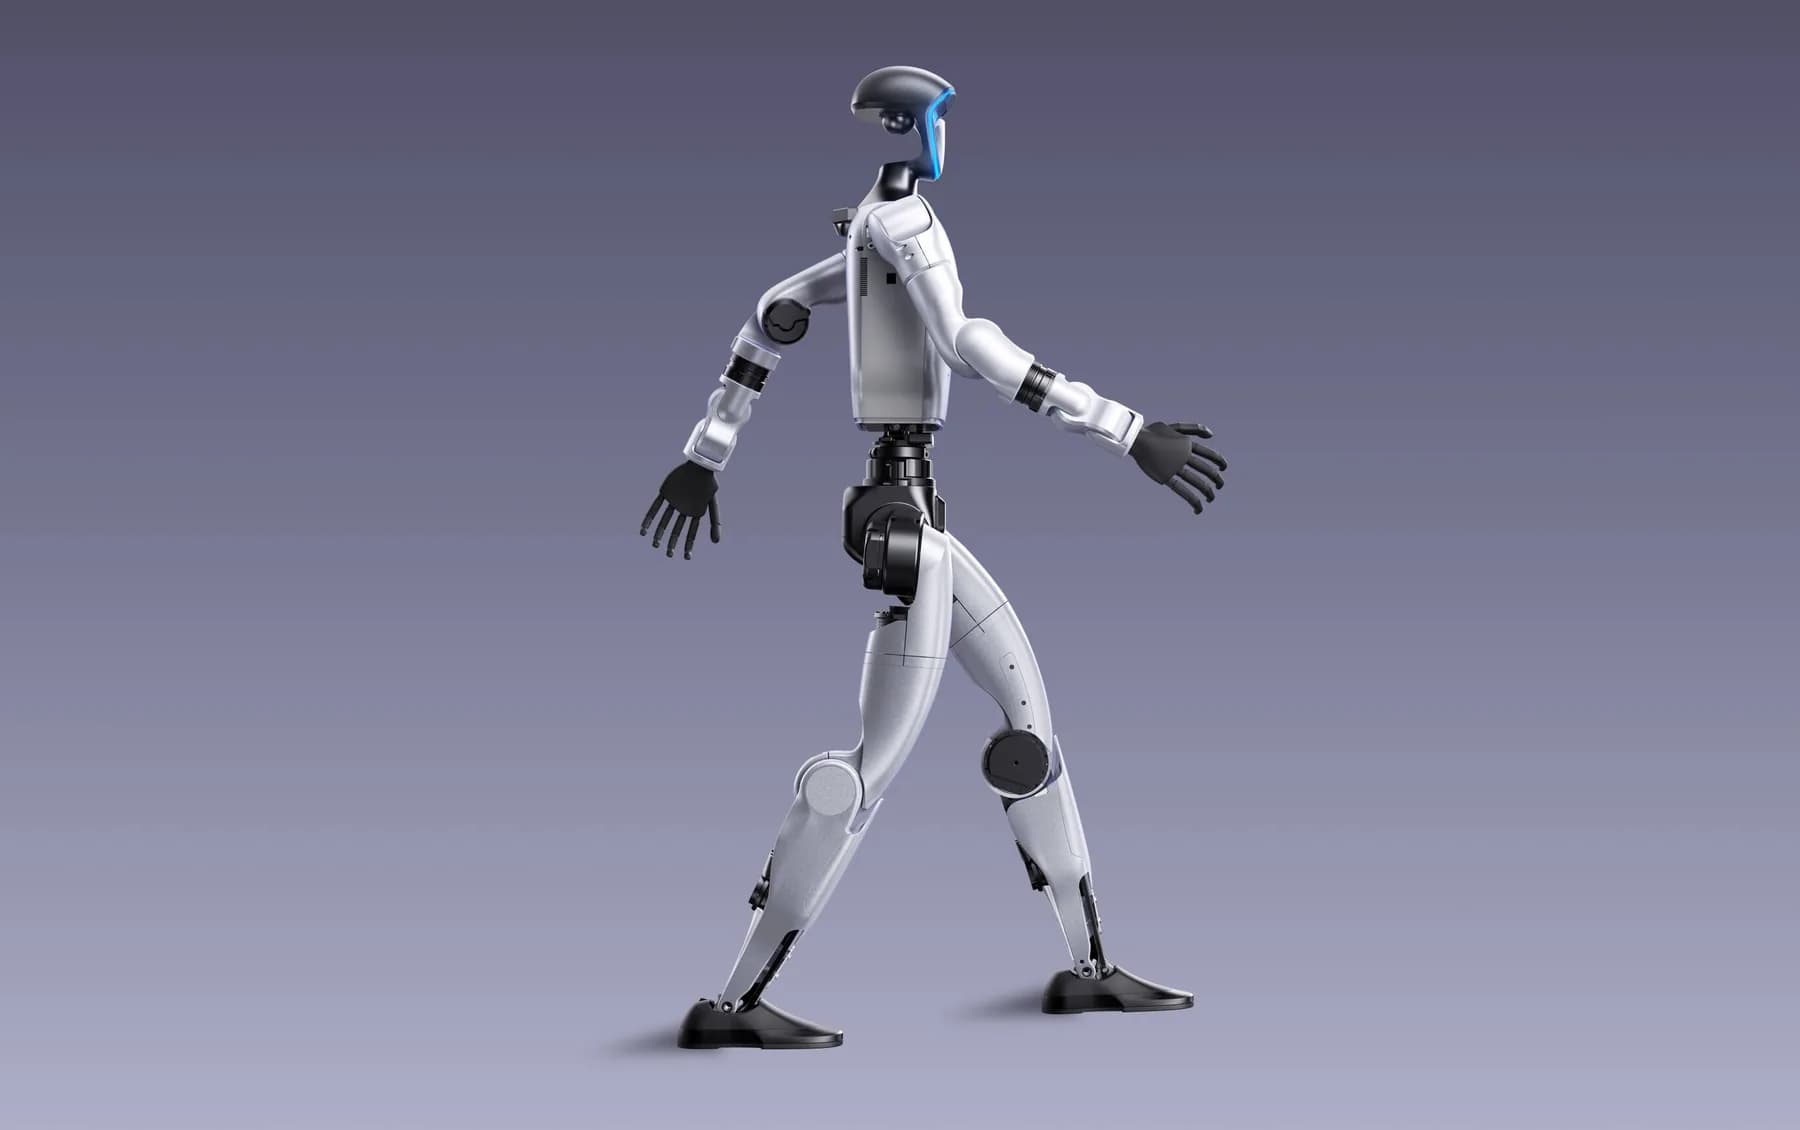
Unitree
G1
Unitree's second humanoid robot and first small-scale model, launched on May 13, 2024 and billed by the compan…
Height132 cm
Degrees of freedom23
Arm payload2 kg
ResearchIndustrial
CN¥99,000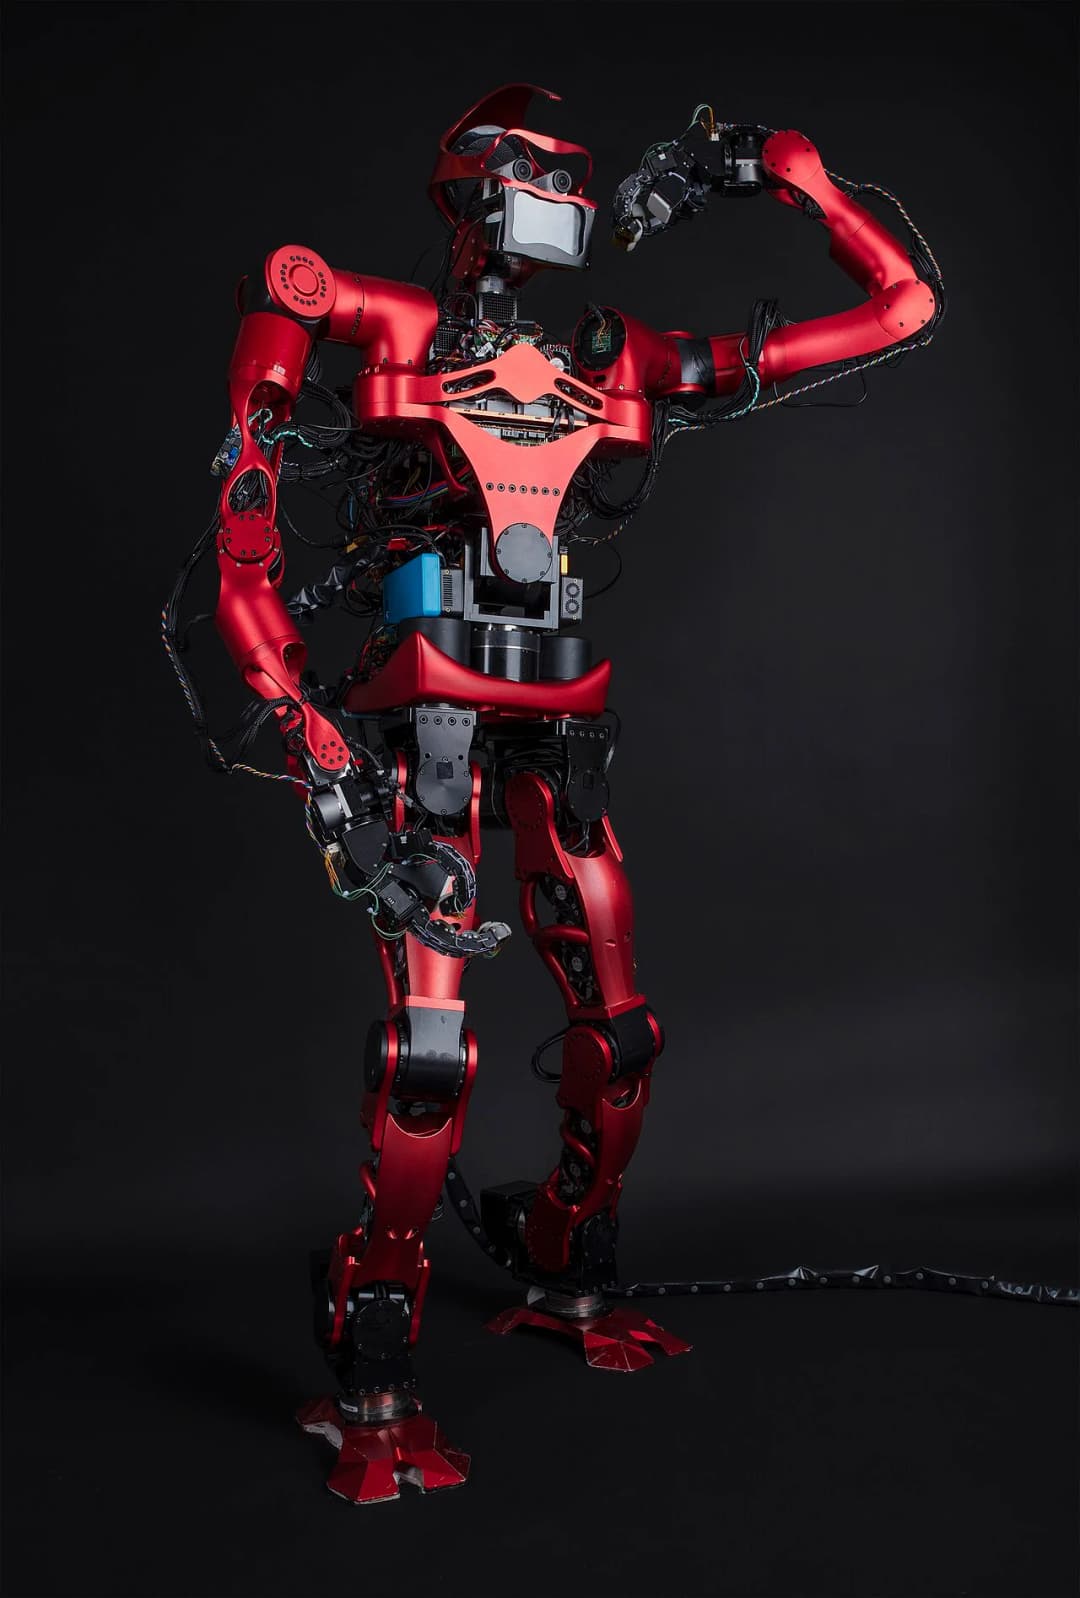
A torque-controlled full-size humanoid built as a walking avatar for remote operation.
TOCABI (Torque-controlled CompliAnt BIped) is a 1.8 m, 100 kg, 33-DOF humanoid developed at Seoul National University's DYROS laboratory under Professor Jaeheung Park, with industrial design from NJIT. The lower body was built from 2013-2014 and the upper body completed in 2021, when the robot debuted at the ANA Avatar XPRIZE semifinals as a full-size avatar that streams stereo vision and audio to a VR operator. It is often misattributed to KAIST, but the project and team are based at SNU. Torque sensing at every joint and compliance control are central to its design for safe physical interaction.
| Height | 180 cm |
|---|---|
| Weight | 100 kg |
| Form factor | Full-size |
| Locomotion | Bipedal |
|---|---|
| Degrees of freedom | 33 |
| DOF breakdown | 33 DOF total across legs, arms, torso, neck and hands; per-chain breakdown is not published. |
| Actuators | Custom torque-controlled electric actuators with joint torque sensing, designed and built by the team. |
| Compute | Real-time whole-body control computer running hierarchical quadratic programming (HQP); detailed hardware is not published. |
|---|---|
| Sensing | Head cameras and microphones for avatar telepresence, joint torque sensors and encoders, inertial sensing. |
| Hands | Multi-fingered hands used for avatar manipulation; hand DOF is not published. |
| Availability | Research prototype only; not commercially available. |
|---|---|
| Target market | Academic and industrial humanoid research. |
| Software / OS | Custom real-time whole-body control framework with HQP-based task prioritisation; ROS tooling used in research. |
| Deployments & partners | Seoul National University laboratories; demonstrated at the ANA Avatar XPRIZE. |
| Safety & certifications | Torque control and compliant joint behaviour limit the energy released during contact. |
Claims on this profile are linked to primary reporting and manufacturer material where available.
Specifications are sourced from public materials and may change. Always confirm commercial terms with the manufacturer.
Unitree's second humanoid robot and first small-scale model, launched on May 13, 2024 and billed by the compan…
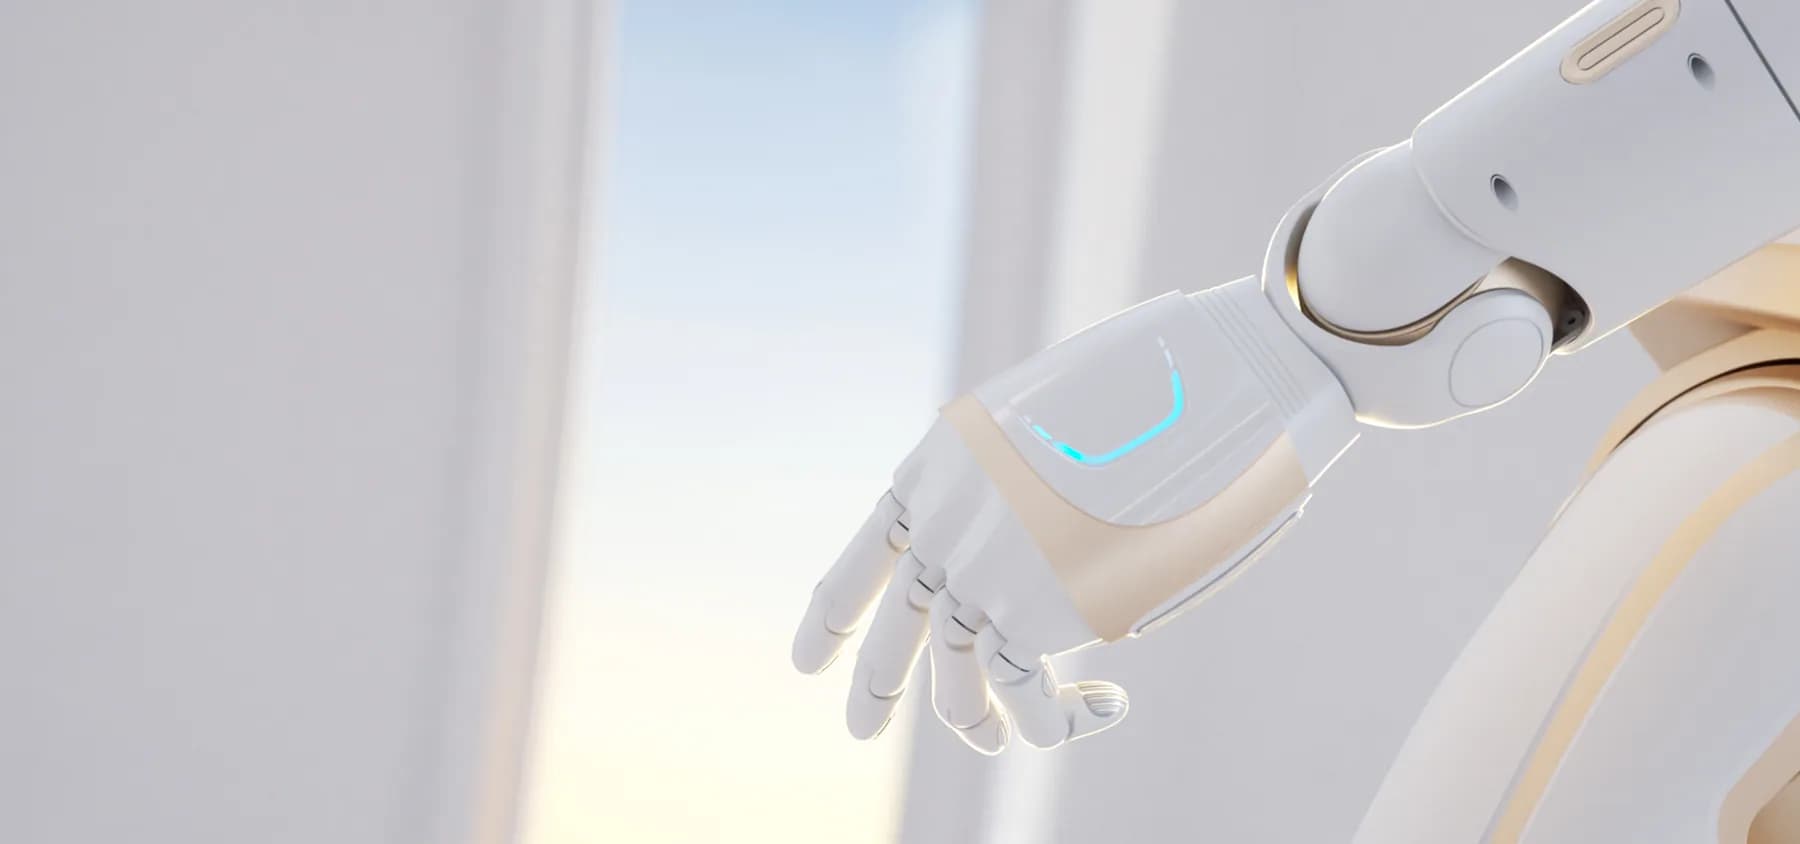
UBTech's next-generation large humanoid service robot, globally unveiled at WAIC 2021 in Shanghai on July 7, 2…
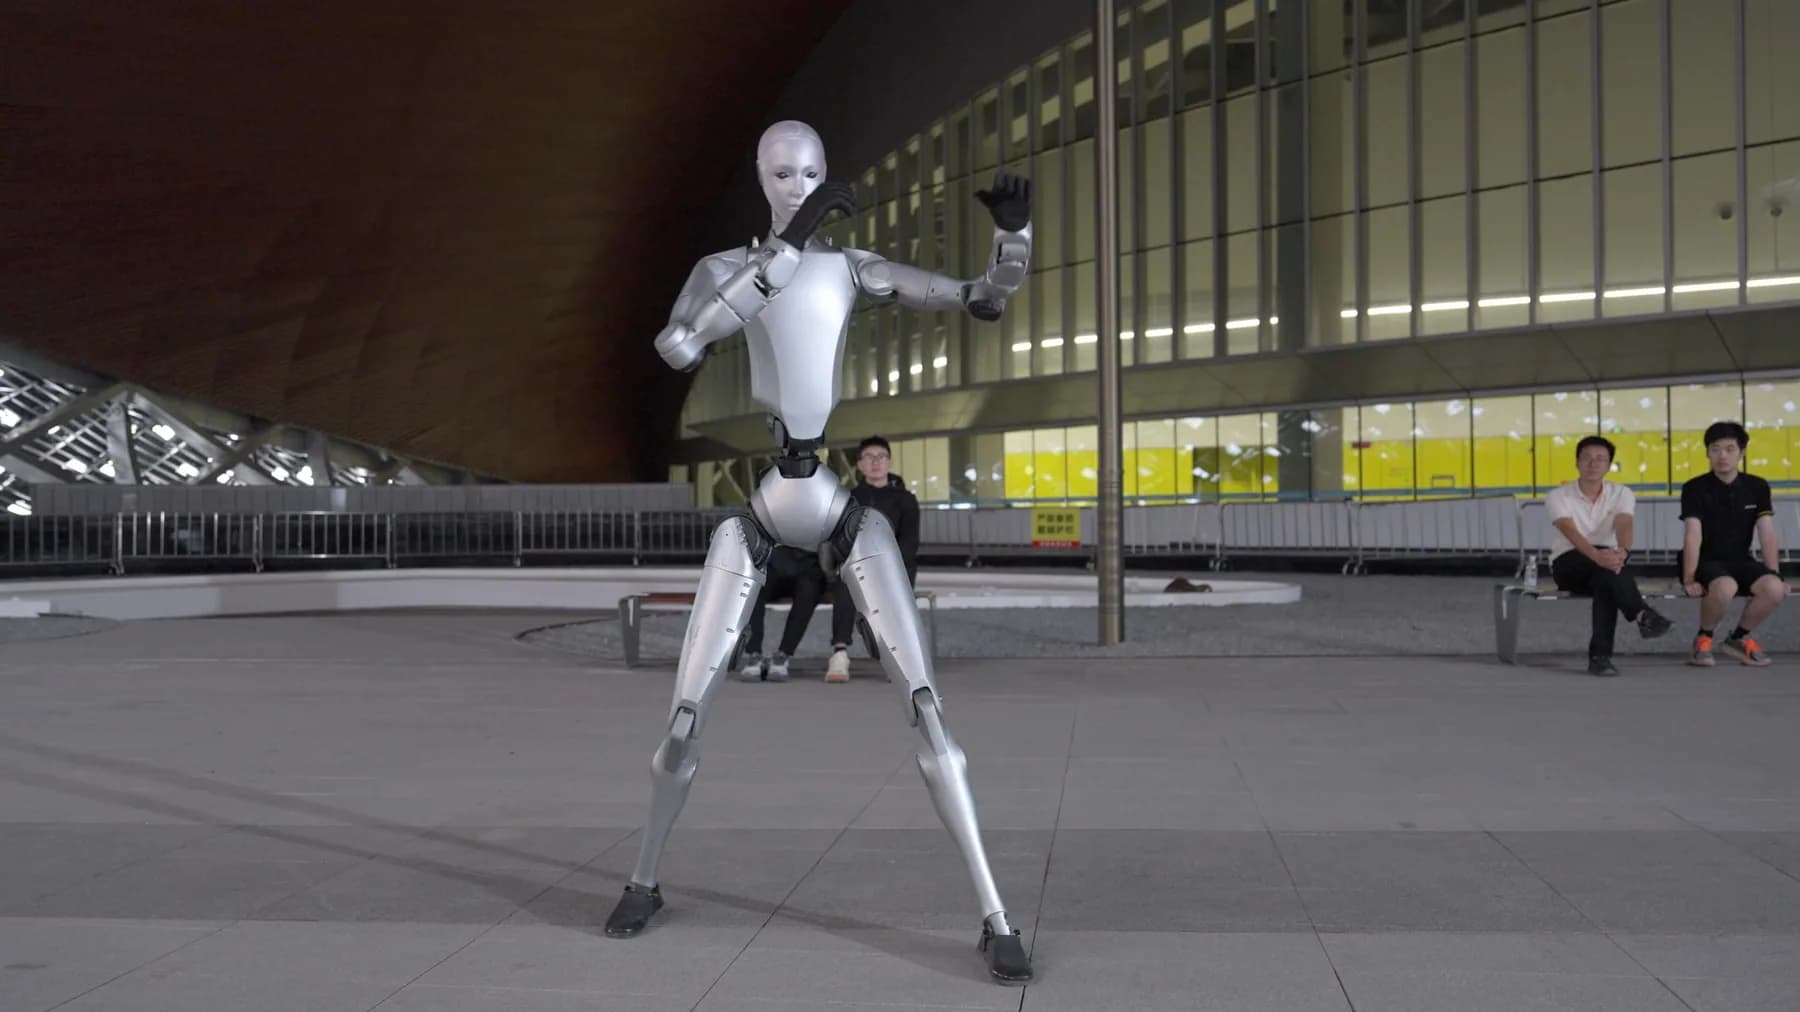
Unitree's fourth humanoid robot and second full-size model after the H1, launched on October 20, 2025 and desc…
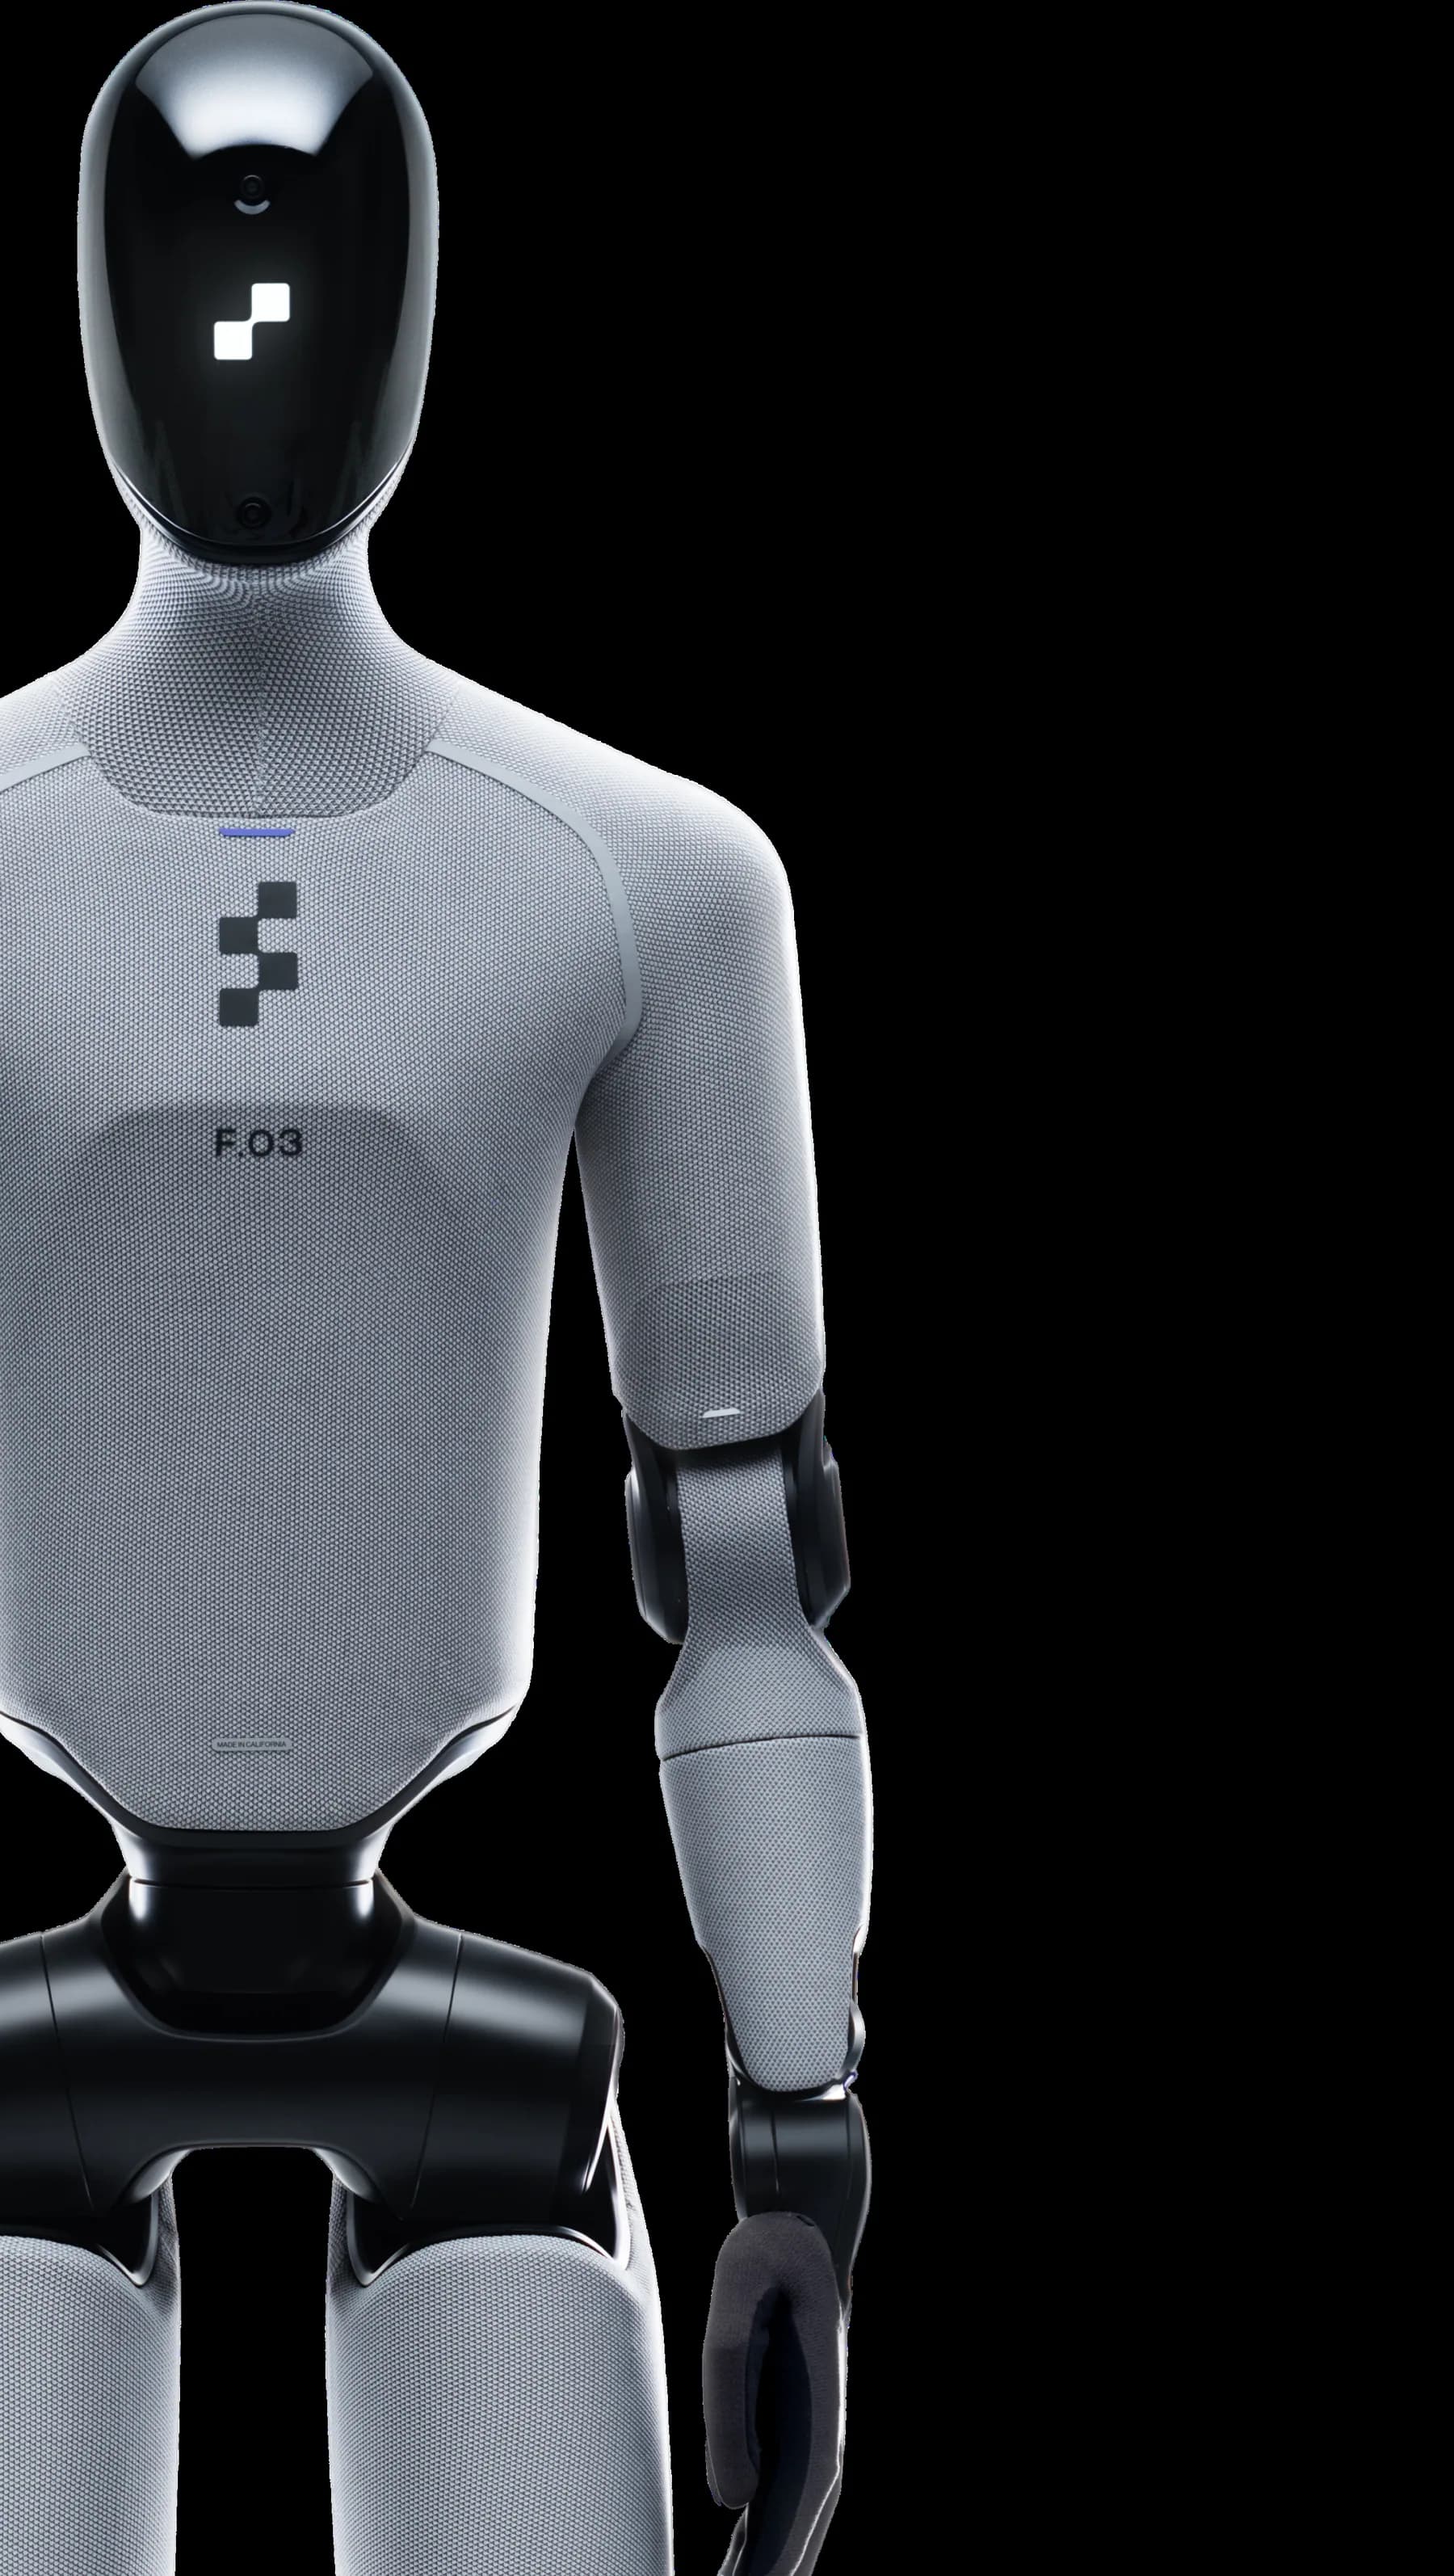
Figure 03 was officially launched on October 9, 2025, the same day as its TIME Best Inventions cover, and is F…